


Journal of Computer Applications ›› 2026, Vol. 46 ›› Issue (10): 3180-3190.DOI: 10.11772/j.issn.1001-9081.2025091132
• Data science and technology • Previous Articles
Rui ZHANG1( ), Zhicheng ZHENG1, Lihu PAN1, Huanyuan GUO1, Linliang ZHANG2, Huimin YAN3
Received:2025-09-26
Revised:2025-12-09
Accepted:2025-12-10
Online:2025-12-22
Published:2026-10-10
Contact:
Rui ZHANG
About author:ZHENG Zhicheng, born in 2002, M. S. candidate. His research interests include multi-agent simulation.Supported by:
张睿1(), 郑至诚1, 潘理虎1, 郭桓渊1, 张林梁2, 闫慧敏3
通讯作者:
张睿
作者简介:郑至诚(2002—),男,安徽阜阳人,硕士研究生,主要研究方向:多智能体仿真基金资助:CLC Number:
Rui ZHANG, Zhicheng ZHENG, Lihu PAN, Huanyuan GUO, Linliang ZHANG, Huimin YAN. Mesoscale modeling-based multi-agent simulation method for dynamic traffic[J]. Journal of Computer Applications, 2026, 46(10): 3180-3190.
张睿, 郑至诚, 潘理虎, 郭桓渊, 张林梁, 闫慧敏. 基于介尺度建模的动态交通多智能体仿真方法[J]. 《计算机应用》唯一官方网站, 2026, 46(10): 3180-3190.
Add to citation manager EndNote|Ris|BibTeX
URL: https://www.joca.cn/EN/10.11772/j.issn.1001-9081.2025091132
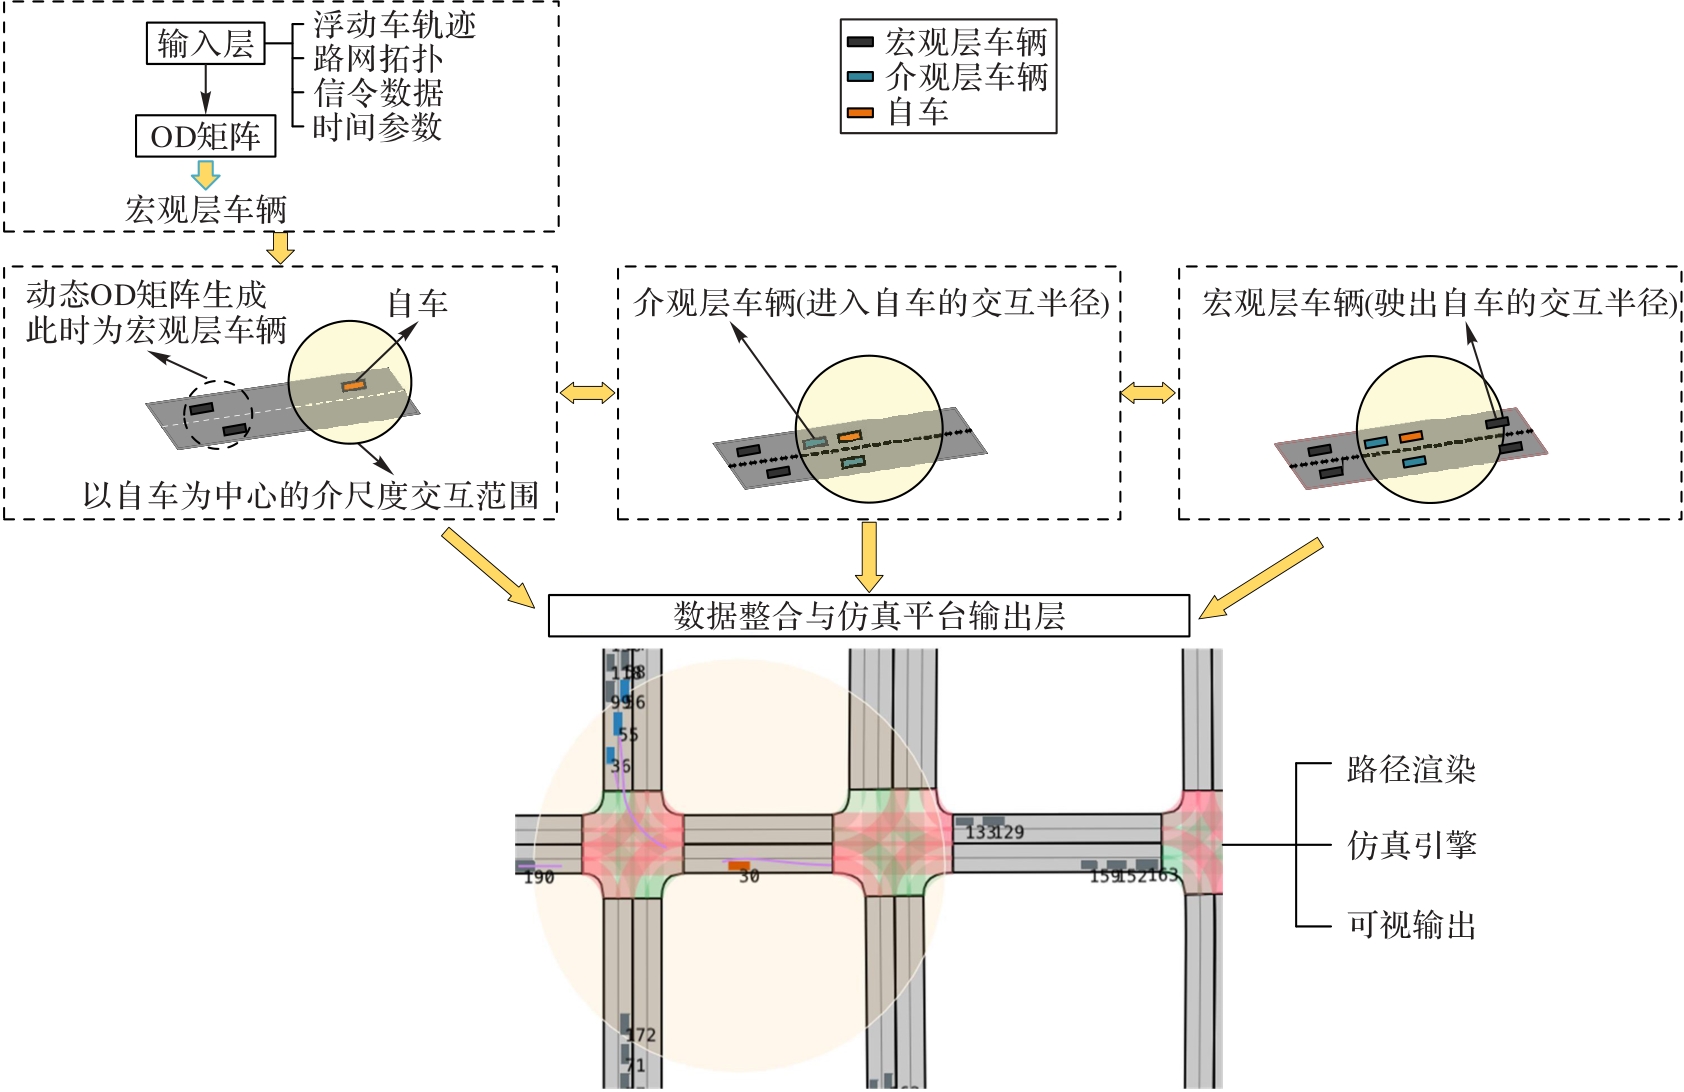
Fig. 1 System framework
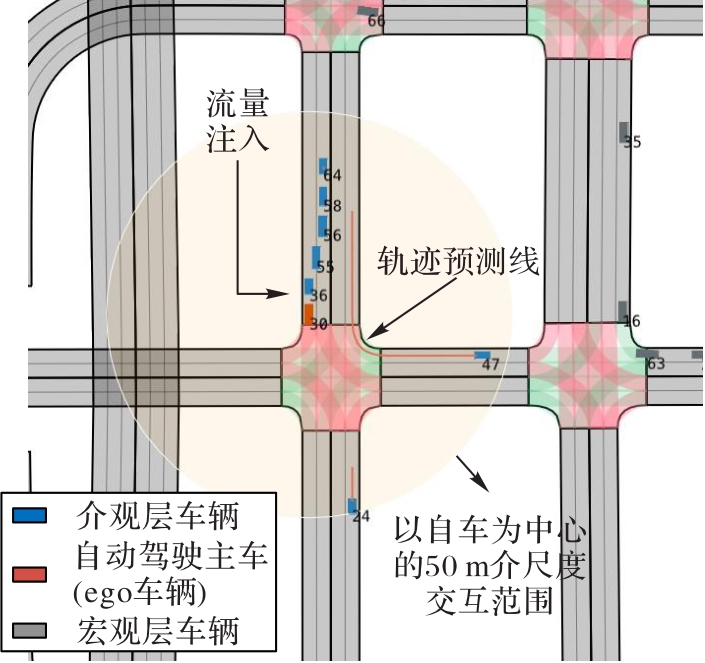
Fig. 2 Schematic diagram of scale partitioning
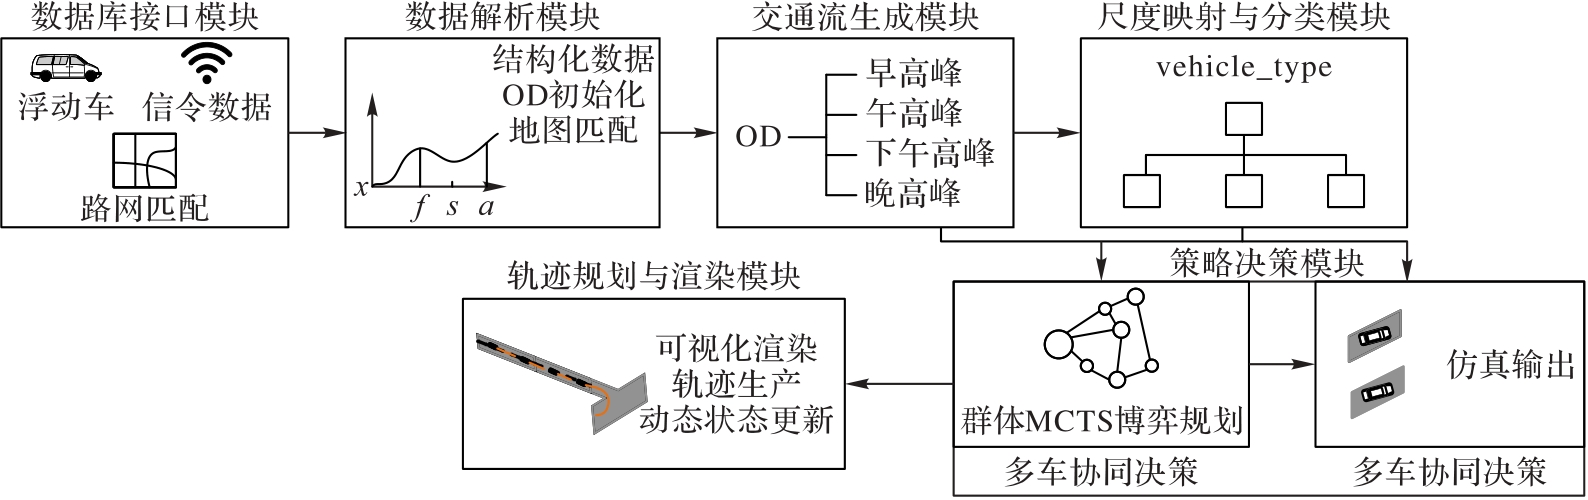
Fig. 3 Framework of multi-scale traffic simulation modeling
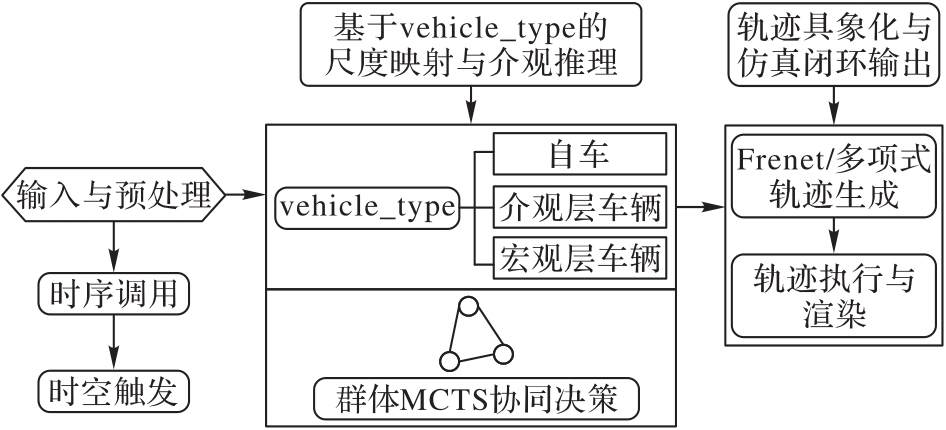
Fig. 4 Structure of spatio-temporal coupling-based micro-meso-macro traffic simulation system
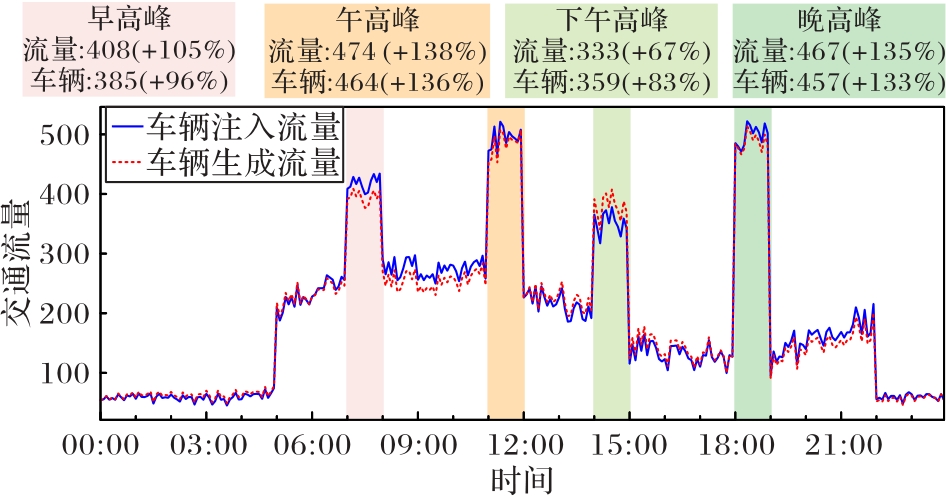
Fig. 5 Daily variation trends of vehicle generation flow and injection flow in simulation system
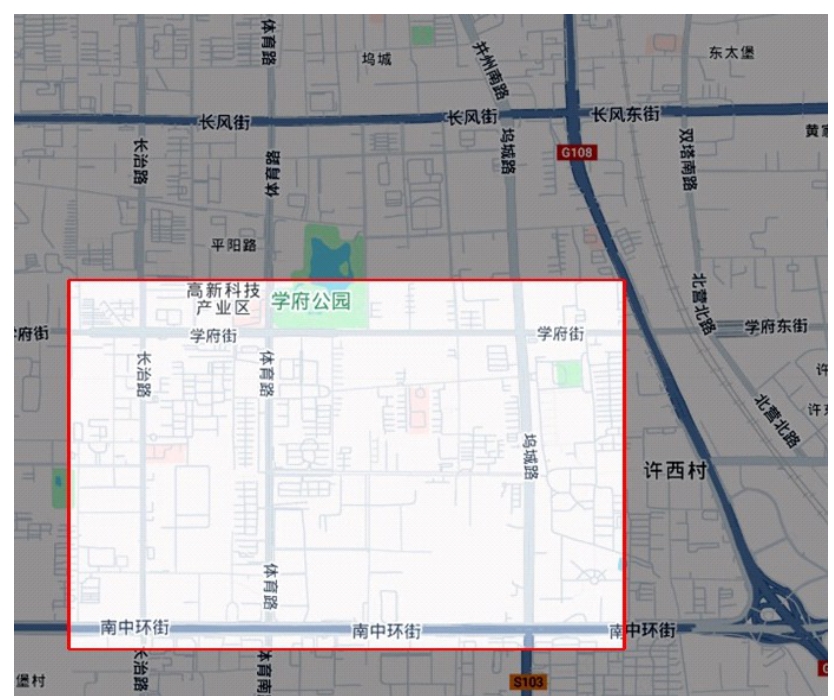
Fig. 6 Target study area
| 项目 | 设置 |
|---|---|
| 硬件环境 | Intel i7-9700k ×8线程,16 GB RAM,Windows 11 |
| 软件依赖 | Python 3.10,SUMO 1.16,LimSim |
| 地图数据 | 太原市主城区主干路提取子路(约12 km×12 km) |
| 车辆规模 | 峰值控制车辆数800~1 000 |
| 仿真时长 | 全天24 h(加速模式下运行5 min) |
Tab. 1 Experimental environment and configuration
| 项目 | 设置 |
|---|---|
| 硬件环境 | Intel i7-9700k ×8线程,16 GB RAM,Windows 11 |
| 软件依赖 | Python 3.10,SUMO 1.16,LimSim |
| 地图数据 | 太原市主城区主干路提取子路(约12 km×12 km) |
| 车辆规模 | 峰值控制车辆数800~1 000 |
| 仿真时长 | 全天24 h(加速模式下运行5 min) |
| 指标 | 含义 |
|---|---|
| 轨迹平滑度 | 单车轨迹变化的标准差,反映运动物理合理性 |
| 平均通行时间 | 从起点到终点的时间(单位:s),反映系统交通效率 |
| 冲突率 | 同一交通区域内轨迹重叠或过近次数,反映局部 决策协同性 |
| 系统帧率 | 每秒仿真帧数,表示系统运行速度与稳定性 |
| 内存占用 | 峰值RAM占用,表示大规模仿真资源开销 |
Tab. 2 Traffic performance indicators
| 指标 | 含义 |
|---|---|
| 轨迹平滑度 | 单车轨迹变化的标准差,反映运动物理合理性 |
| 平均通行时间 | 从起点到终点的时间(单位:s),反映系统交通效率 |
| 冲突率 | 同一交通区域内轨迹重叠或过近次数,反映局部 决策协同性 |
| 系统帧率 | 每秒仿真帧数,表示系统运行速度与稳定性 |
| 内存占用 | 峰值RAM占用,表示大规模仿真资源开销 |
| 方案 | 控制策略 | 特点 |
|---|---|---|
| A | 所有车辆使用微观独立规划 | 无协同+轨迹重叠严重,控制稳定性差(交通时段不为动态) |
| B | 引入介尺度协同规划机制 | 中心区域轨迹连续,交互车辆冲突减少(交通时段不为动态) |
| C | 引入介尺度+时段OD调度机制 | 模拟全天流量波动,仿真更贴近实际(交通时段为动态) |
Tab. 3 Detailed comparison of different schemes
| 方案 | 控制策略 | 特点 |
|---|---|---|
| A | 所有车辆使用微观独立规划 | 无协同+轨迹重叠严重,控制稳定性差(交通时段不为动态) |
| B | 引入介尺度协同规划机制 | 中心区域轨迹连续,交互车辆冲突减少(交通时段不为动态) |
| C | 引入介尺度+时段OD调度机制 | 模拟全天流量波动,仿真更贴近实际(交通时段为动态) |
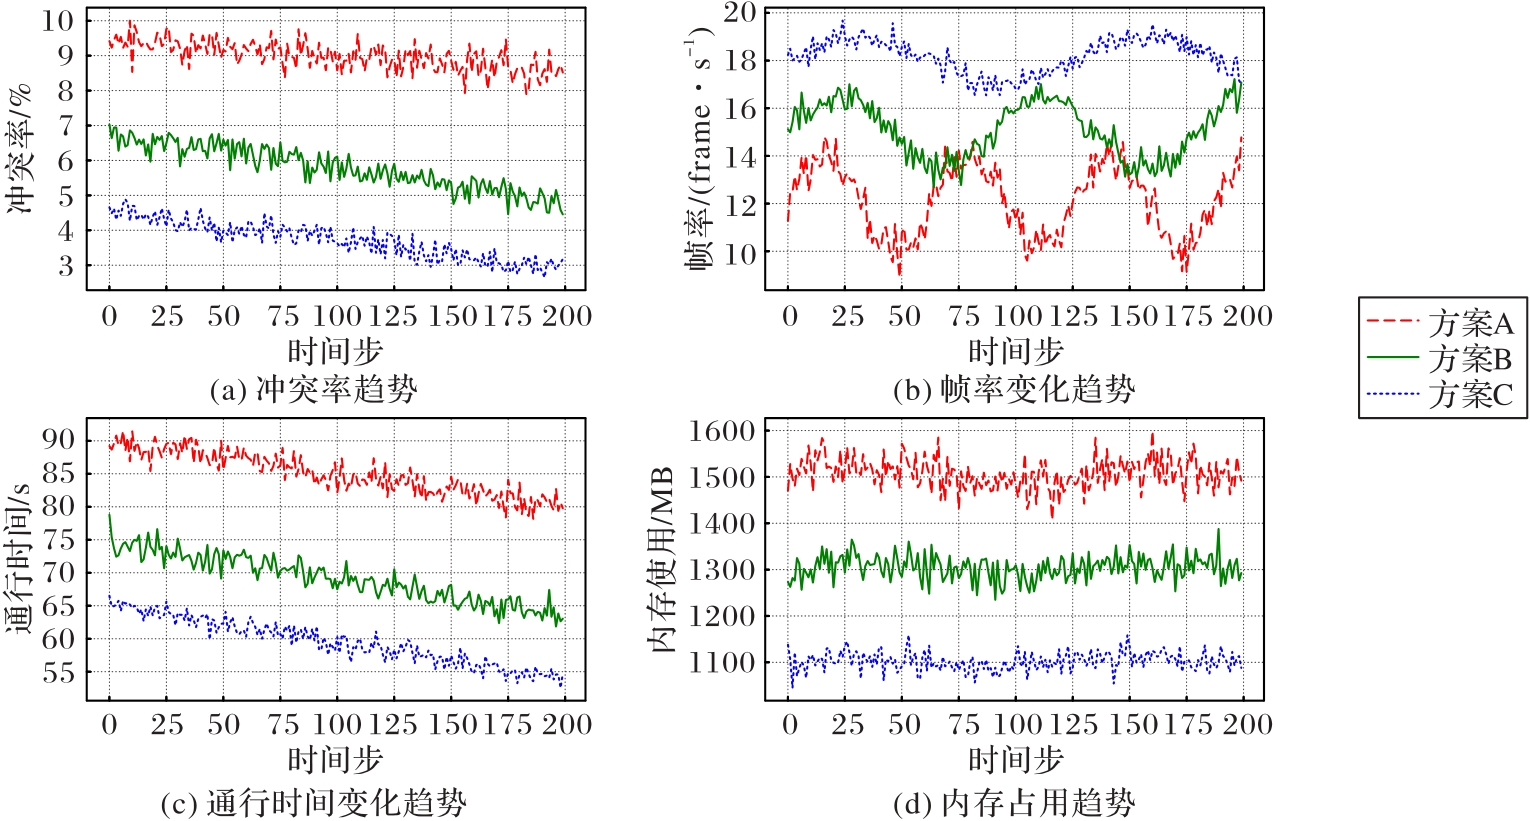
Fig. 7 Dynamic evolution trajectories of different schemes
| 方案 | 轨迹偏差/m | 交互冲突率/% | 控制稳定性得分 | 仿真误差/% |
|---|---|---|---|---|
| A | 4.8 | 23 | 60 | 21.0 |
| B | 2.8 | 13 | 78 | 12.0 |
| C | 1.5 | 6 | 89 | 5.0 |
Tab. 4 Data comparison of different schemes
| 方案 | 轨迹偏差/m | 交互冲突率/% | 控制稳定性得分 | 仿真误差/% |
|---|---|---|---|---|
| A | 4.8 | 23 | 60 | 21.0 |
| B | 2.8 | 13 | 78 | 12.0 |
| C | 1.5 | 6 | 89 | 5.0 |
| 平台 | 仿真精度 | 系统效率 | 场景响应能力 |
|---|---|---|---|
| 本文平台 | 0.95 | 0.89 | 0.92 |
| SUMO | 0.84 | 0.65 | 0.58 |
| PTV VISSIM | 0.81 | 0.58 | 0.52 |
| CityFlow | 0.87 | 0.71 | 0.61 |
Tab. 5 Comparison of different simulation platforms on three performance indicators
| 平台 | 仿真精度 | 系统效率 | 场景响应能力 |
|---|---|---|---|
| 本文平台 | 0.95 | 0.89 | 0.92 |
| SUMO | 0.84 | 0.65 | 0.58 |
| PTV VISSIM | 0.81 | 0.58 | 0.52 |
| CityFlow | 0.87 | 0.71 | 0.61 |
| 平台 | 恢复时间步数 | 平均队列长度/m | 通行率下降率% |
|---|---|---|---|
| 本文平台 | 350.0 | 42.1 | 7.8 |
| SUMO | 610.0 | 75.4 | 18.5 |
| PTV VISSIM | 500.0 | 64.7 | 13.3 |
| CityFlow | 580.0 | 70.8 | 15.2 |
Tab. 6 Robustness comparison of different platforms under emergency disturbance condition
| 平台 | 恢复时间步数 | 平均队列长度/m | 通行率下降率% |
|---|---|---|---|
| 本文平台 | 350.0 | 42.1 | 7.8 |
| SUMO | 610.0 | 75.4 | 18.5 |
| PTV VISSIM | 500.0 | 64.7 | 13.3 |
| CityFlow | 580.0 | 70.8 | 15.2 |
| [1] | Wang S H, Tu C H, Juang J C. Automatic traffic modelling for creating digital twins to facilitate autonomous vehicle development[J]. Connection Science, 2022, 34(1): 1018-1037. |
| [2] | Argota Sánchez-Vaquerizo J. Getting real: the challenge of building and validating a large-scale digital twin of Barcelona’s traffic with empirical data[J]. ISPRS International Journal of Geo-Information, 2022, 11(1): No.24. |
| [3] | Alghamdi T, Mostafi S, Abdelkader G, et al. A comparative study on traffic modeling techniques for predicting and simulating traffic behavior[J]. Future Internet, 2022, 14(10): No.294. |
| [4] | Cheng Z, Wang X, Chen X, et al. Bayesian calibration of traffic flow fundamental diagrams using Gaussian processes[J]. IEEE Open Journal of Intelligent Transportation Systems, 2022, 3: 763-771. |
| [5] | Kim Y, Choi S, Park J, et al. Agent-based mesoscopic urban traffic simulation based on multi-lane cell transmission model[J]. Procedia Computer Science, 2019, 151: 240-247. |
| [6] | Li H, Dong W, Lu L, et al. Distributed cooperative driving strategy for connected automated vehicles at unsignalized intersections based on Monte Carlo method[J]. Journal of Advanced Transportation, 2024, 2024: No.6586774. |
| [7] | Zhang Z, Yang J, Zha H. Integrating independent and centralized multi-agent reinforcement learning for traffic signal network optimization[C]// AAMAS 2020. Richland, SC: International Foundation for Autonomous Agents and Multiagent Systems, 2020: 2083-2085. |
| [8] | Fang J, You Y, Xu M, et al. Multi-objective traffic signal control using network-wide agent coordinated reinforcement learning[J]. Expert Systems with Applications, 2023, 229(Pt A): No.120535. |
| [9] | Hu K, Wen M, Wang X, et al. PMAT: optimizing action generation order in multi-agent reinforcement learning[C]// AAMAS 2025. Richland, SC: International Foundation for Autonomous Agents and Multiagent Systems, 2025: 997-1005. |
| [10] | Chen D, Hajidavalloo M R, Li Z, et al. Deep multi-agent reinforcement learning for highway on-ramp merging in mixed traffic[J]. IEEE Transactions on Intelligent Transportation Systems, 2023, 24(11): 11623-11638. |
| [11] | Schester L, Ortiz L E. Automated driving highway traffic merging using deep multi-agent reinforcement learning in continuous state-action spaces[C]// IV 2021. Piscataway: IEEE, 2021: 280-287. |
| [12] | Kim J, Lee H, Ko Y M. Constrained Density-Based Spatial Clustering of Applications with Noise (DBSCAN) using hyperparameter optimization[J]. Knowledge-Based Systems, 2024, 303: No.112436. |
| [13] | Xu T, Gao J, Coco G, et al. Urban expansion in Auckland, New Zealand: a GIS simulation via an intelligent self-adapting multiscale agent-based model[J]. International Journal of Geographical Information Science, 2020, 34(11): 2136-2159. |
| [14] | Xie J, Liu Y, Chen N. Two-sided deep reinforcement learning for dynamic mobility-on-demand management with mixed autonomy[J]. Transportation Science, 2023, 57(4): 1019-1046. |
| [15] | 胡明伟,杨文杰. 基于宏微观多尺度建模的校园疫情演化仿真研究[J]. 系统仿真学报, 2024, 36(1): 170-182. |
| Hu Mingwei, Yang Wenjie. Research on campus epidemic evolution based on multi-scale modeling and simulation in microscopic & microscopic view[J]. Journal of System Simulation, 2024, 36(1): 170-182. | |
| [16] | Gao S, Yang J, Chen L, et al. Vista: a generalizable driving world model with high fidelity and versatile controllability[C]// NeurIPS 2024. Red Hook: Curran Associates Inc., 2024: 91560-91596. |
| [17] | Mosteiro-Romero M, Quintana M, Stouffs R, et al. A data-driven agent-based model of occupants’ thermal comfort behaviors for the planning of district-scale flexible work arrangements[J]. Building and Environment, 2024, 257: No.111479. |
| [18] | Che Q, Wang W, Wang F, et al. Structural credit assignment-guided coordinated MCTS: an efficient and scalable method for online multiagent planning[C]// AAMAS 2023. Richland, SC: International Foundation for Autonomous Agents and Multiagent Systems, 2023: 543-551. |
| [19] | Patsatzis D G, di Bernardo M, Russo L, et al. GoRINNs: Godunov-Riemann informed neural networks for learning hyperbolic conservation laws[J]. Journal of Computational Physics, 2025, 534: No.114002. |
| [20] | Liu C, Xu Z, Liu Z, et al. Decentralized multi-vehicle motion planning for platoon forming in mixed traffic using Monte Carlo Tree Search[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(12): 20872-20888. |
| [21] | Zhong Z, Rempe D, Xu D, et al. Guided conditional diffusion for controllable traffic simulation[C]// ICRA 2023. Piscataway: IEEE, 2023: 3560-3566. |
| [22] | Besenczi R, Bátfai N, Jeszenszky P, et al. Large-scale simulation of traffic flow using Markov model[J]. PLoS ONE, 2021, 16(2): No.e0246062. |
| [23] | Chen X, Wu Z, Liang Y. Modeling mixed traffic flow with connected autonomous vehicles and human-driven vehicles in off-ramp diverging areas[J]. Sustainability, 2023, 15(7): No.5651. |
| [24] | Huang Y, Wang X, Liu H, et al. AdaSociety: an adaptive environment with social structures for multi-agent decision-making[C]// NeurIPS 2024. Red Hook: Curran Associates Inc., 2024: 35388-35413. |
| [25] | Storani F, di Pace R, Bruno F, et al. Analysis and comparison of traffic flow models: a new hybrid traffic flow model vs benchmark models[J]. European Transport Research Review, 2021, 13: No.58. |
| [26] | Feng T, Wang W, Yang Y. A survey of world models for autonomous driving[PP/OL]. V3. arXiv (2025-06-19) [2025-08-23].. |
| [1] | Yufeng OU, Chia-Hung WANG. Small-object defect detection method for printed circuit boards based on dual-branch feature extraction [J]. Journal of Computer Applications, 2026, 46(9): 2977-2986. |
| [2] | Kan HE, Hongfeng MA, Xuejun ZONG, Hongyan SHI, Lian LIAN, Bowei NING. DCSFFuzzer: dual-channel semantic feature fusion-based fuzz testing method for industrial control protocols [J]. Journal of Computer Applications, 2026, 46(9): 2877-2888. |
| [3] | Guanliang CHEN, Yi LIU, Yi YU. Heterogeneous multi-agent reinforcement learning enabled co-optimization of UAV 3D obstacle avoidance and edge computing [J]. Journal of Computer Applications, 2026, 46(9): 2898-2909. |
| [4] | Chenyang WANG, Xiaoyu SHI, Jie GAN, Mingsheng SHANG. Trajectory-aware multi-agent cooperative task offloading method for vehicular edge computing [J]. Journal of Computer Applications, 2026, 46(9): 2910-2919. |
| [5] | Hua YAO, Gaoming YANG, Xuelian LI, Kaixuan LU. Remote sensing small object detection with dynamic perception and cross-modulation [J]. Journal of Computer Applications, 2026, 46(9): 2968-2976. |
| [6] | Changqing JI, Ziying ZHANG, Zumin WANG. Continuous non-invasive blood pressure prediction method based on multi-scale Transformer with enhanced graph neural network [J]. Journal of Computer Applications, 2026, 46(9): 3043-3053. |
| [7] | He SUN, Guanghui YAN, Xiaohong JIA. Superpixel segmentation algorithm based on inverted feature pyramid network [J]. Journal of Computer Applications, 2026, 46(9): 2959-2967. |
| [8] | Jiangyan CHEN, Yandan WANG, Yihu LIU, Yinglong MA. Collaborative query optimization-based framework for long-tailed object detection [J]. Journal of Computer Applications, 2026, 46(9): 2769-2775. |
| [9] | Li TANG, Jianyu ZHANG, Rui YAO. Object detection algorithm based on improved YOLOv11 in foggy weather [J]. Journal of Computer Applications, 2026, 46(8): 2630-2639. |
| [10] | Fengchun LIU, Xinying SHAO, Chunying ZHANG, Liya WANG, Jing REN. FCMdepth: monocular depth estimation framework with multi-scale feature optimization [J]. Journal of Computer Applications, 2026, 46(8): 2603-2611. |
| [11] | Jingying XUE, Liqun KUANG, Zhixun WANG, Zhengtao GUO, Huiyan HAN. Multi-agent path planning with hierarchical adaptive implicit quantiles [J]. Journal of Computer Applications, 2026, 46(8): 2533-2540. |
| [12] | Jielong BAI, Chenyun FANG, Zhiwei QIAO. Sparse CT artifact suppresion Transformer network based on multi-scale attention adaptive fusion [J]. Journal of Computer Applications, 2026, 46(8): 2660-2667. |
| [13] | Guanghui LI, Licheng QU. Dynamic dilated convolution and hierarchical local-global attention model based on improved Lite-Mono architecture [J]. Journal of Computer Applications, 2026, 46(8): 2567-2576. |
| [14] | Juan CHEN, Yujie CHEN, Zongling WU, Di TIAN, Jie ZHONG. User-centric satellite edge computing architecture for task offloading optimization [J]. Journal of Computer Applications, 2026, 46(8): 2524-2532. |
| [15] | Lin HUANG, Yingshun LI, Weiyan TONG, Shuyuan ZHANG, Zihan WANG. Remote sensing image object detection algorithm based on improved real-time detection Transformer [J]. Journal of Computer Applications, 2026, 46(8): 2652-2659. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
