


Journal of Computer Applications ›› 2026, Vol. 46 ›› Issue (9): 2987-2995.DOI: 10.11772/j.issn.1001-9081.2025080989
• Multimedia computing and computer simulation • Previous Articles
Aoyun YAN1, Linglong ZHU2,3( )
Received:2025-08-27
Revised:2025-11-18
Accepted:2025-11-27
Online:2025-12-01
Published:2026-09-10
Contact:
Linglong ZHU
About author:YAN Aoyun, born in 2001, M. S. candidate. His research interests include computer vision.Supported by:
闫奥运1, 朱灵龙2,3()
通讯作者:
朱灵龙
作者简介:闫奥运(2001—),男,安徽宿州人,硕士研究生,主要研究方向:计算机视觉基金资助:CLC Number:
Aoyun YAN, Linglong ZHU. REL-YOLO: lightweight road waterlogging detection network integrating reflection perception features[J]. Journal of Computer Applications, 2026, 46(9): 2987-2995.
闫奥运, 朱灵龙. 轻量级融合反射感知特征的道路积水检测网络REL-YOLO[J]. 《计算机应用》唯一官方网站, 2026, 46(9): 2987-2995.
Add to citation manager EndNote|Ris|BibTeX
URL: https://www.joca.cn/EN/10.11772/j.issn.1001-9081.2025080989
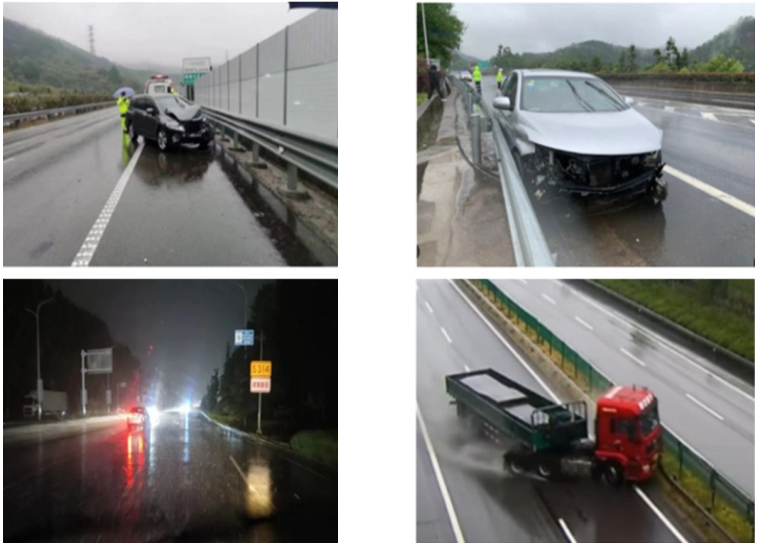
Fig. 1 Examples of typical traffic accidents caused by road waterlogging
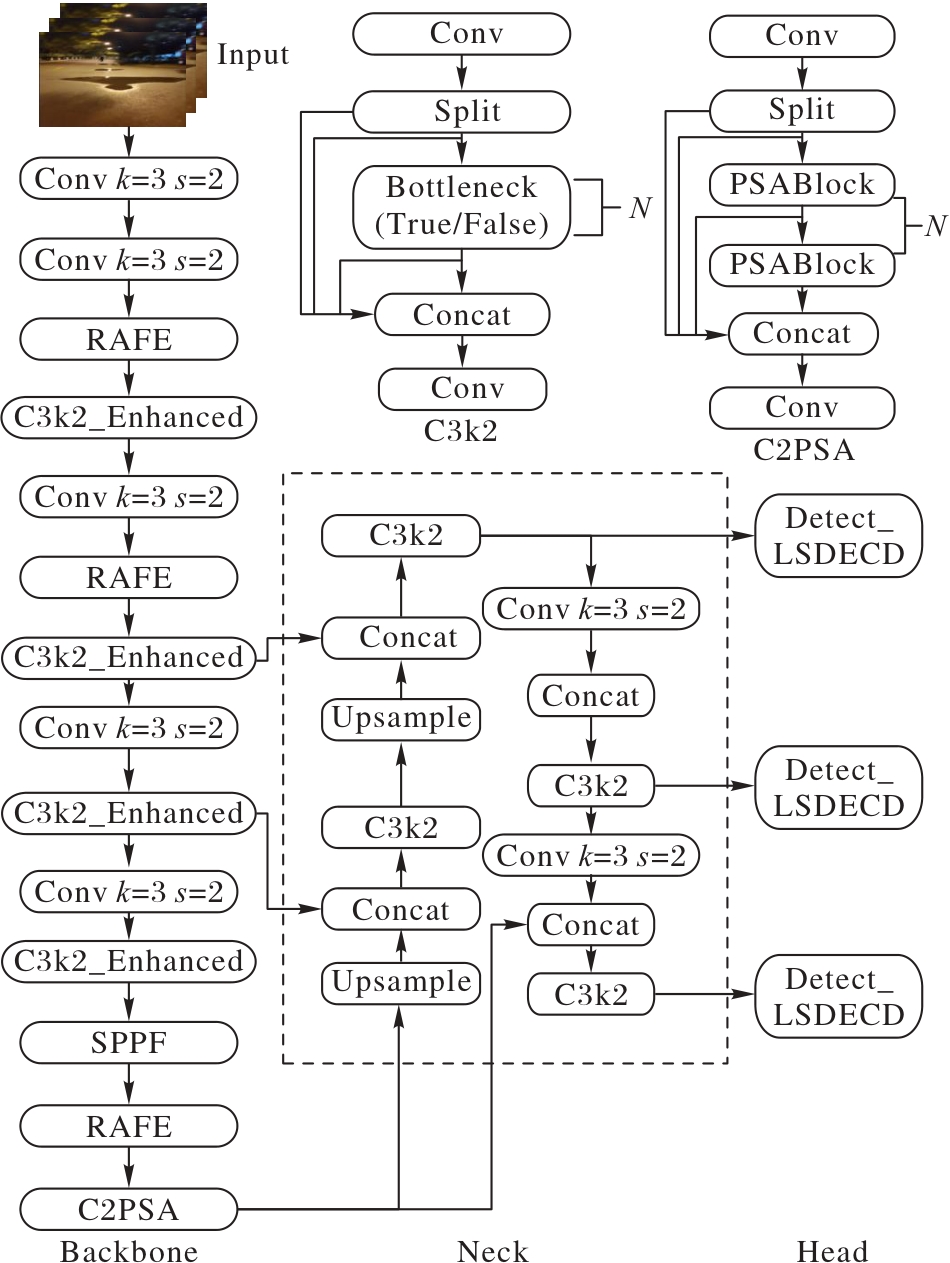
Fig. 2 Network structure of REL-YOLO model
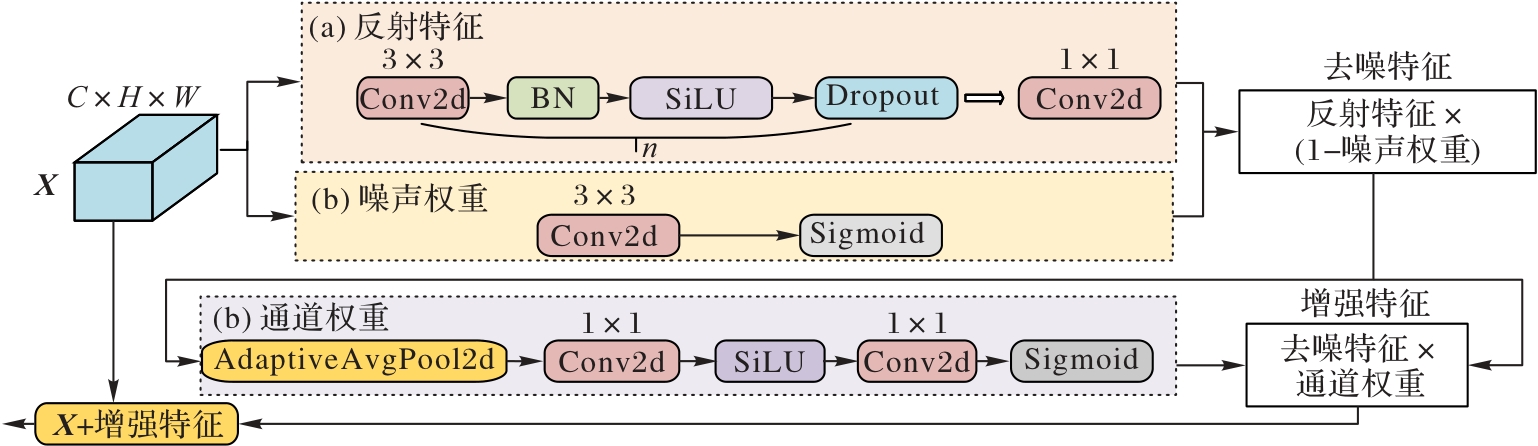
Fig. 3 Network structure of RAFE module
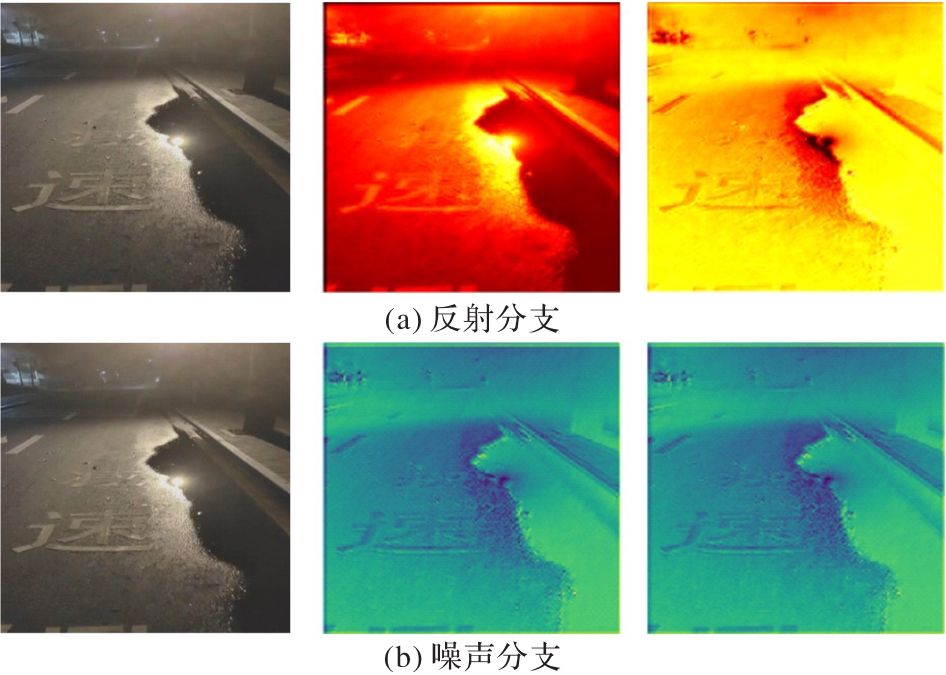
Fig. 4 Visualization results of reflection branch and noise branch
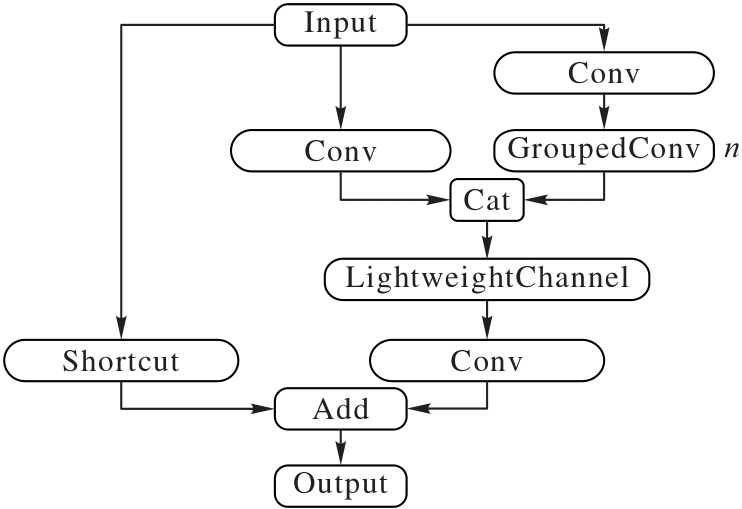
Fig. 5 Structure of C3k2_Enhanced module
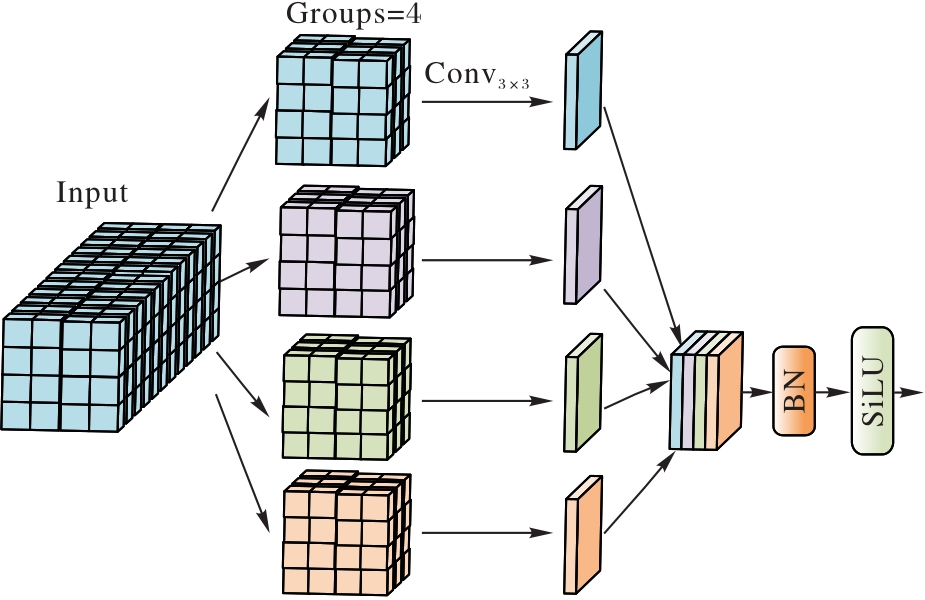
Fig. 6 Structure of grouped convolution
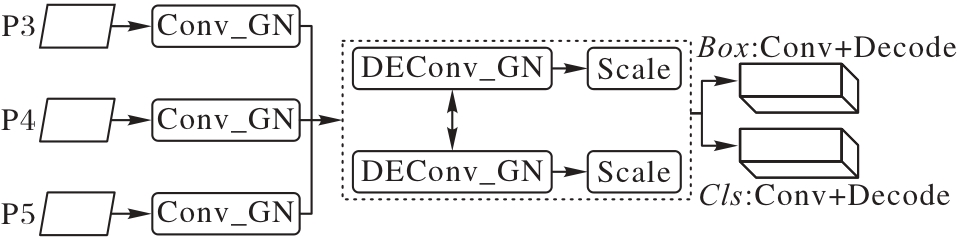
Fig. 7 Network structure of Detect_LSDECD
| 项目 | 配置 |
|---|---|
| 操作系统 | Windows 10 22H |
| 编程语言 | Python 3.10 |
| 深度学习框架 | PyTorch 2.0.1 |
| 并行计算平台 | CUDA 12.1 |
| CPU | Intel 酷睿 i5-12400F |
| GPU | RTX 4060Ti (16 GB) |
| 内存 | 32 GB |
Tab. 1 Experimental environment
| 项目 | 配置 |
|---|---|
| 操作系统 | Windows 10 22H |
| 编程语言 | Python 3.10 |
| 深度学习框架 | PyTorch 2.0.1 |
| 并行计算平台 | CUDA 12.1 |
| CPU | Intel 酷睿 i5-12400F |
| GPU | RTX 4060Ti (16 GB) |
| 内存 | 32 GB |
| 参数 | 值 | 参数 | 值 |
|---|---|---|---|
| Learning rate | 0.01 | Batch size | 32 |
| Image size | 640×640 | Epoch | 250 |
| Momentum | 0.937 | Weight decay | 0.000 5 |
| Optimizer | SGD |
Tab. 2 Training hyperparameters
| 参数 | 值 | 参数 | 值 |
|---|---|---|---|
| Learning rate | 0.01 | Batch size | 32 |
| Image size | 640×640 | Epoch | 250 |
| Momentum | 0.937 | Weight decay | 0.000 5 |
| Optimizer | SGD |
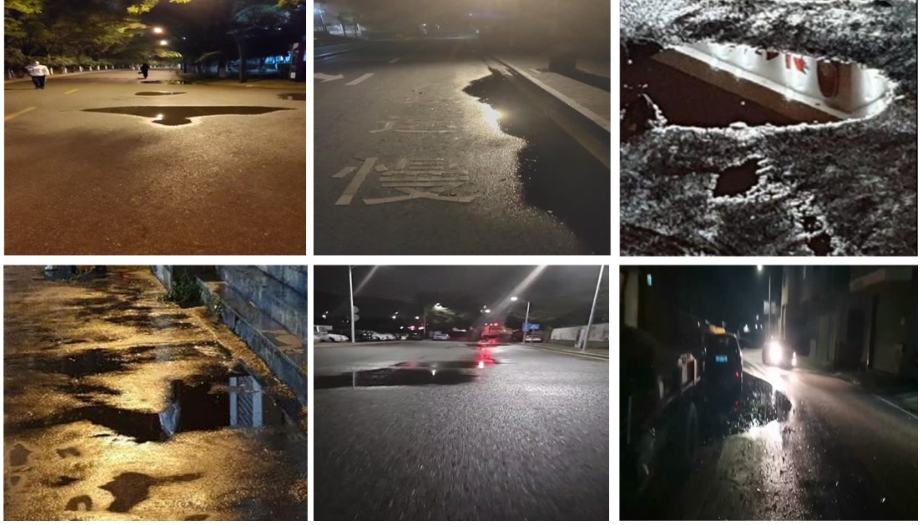
Fig. 8 Examples of Road waterlogging dataset (nighttime)
| 模型 | Precision/% | Recall/% | mAP@50/% | mAP@50:95/% | 参数量/106 | 浮点运算量/GFLOPs | 检测速度/(frame·s-1) |
|---|---|---|---|---|---|---|---|
| YOLOv8n | 84.3 | 78.0 | 85.3 | 47.2 | 3.01 | 8.1 | 305 |
| YOLOv9t | 84.0 | 73.3 | 82.0 | 49.0 | 2.00 | 7.6 | 251 |
| YOLOv10n | 81.6 | 76.4 | 83.3 | 43.2 | 2.26 | 6.5 | 286 |
| YOLOv11n | 91.0 | 78.1 | 86.3 | 48.2 | 2.60 | 6.3 | 284 |
| YOLOv12n | 86.2 | 77.5 | 85.1 | 47.4 | 2.52 | 6.0 | 182 |
| REL-YOLO | 88.9 | 80.0 | 87.6 | 48.0 | 2.26 | 4.3 | 242 |
Tab. 3 Comparison of evaluation indicators of different models on Puddle detection dataset
| 模型 | Precision/% | Recall/% | mAP@50/% | mAP@50:95/% | 参数量/106 | 浮点运算量/GFLOPs | 检测速度/(frame·s-1) |
|---|---|---|---|---|---|---|---|
| YOLOv8n | 84.3 | 78.0 | 85.3 | 47.2 | 3.01 | 8.1 | 305 |
| YOLOv9t | 84.0 | 73.3 | 82.0 | 49.0 | 2.00 | 7.6 | 251 |
| YOLOv10n | 81.6 | 76.4 | 83.3 | 43.2 | 2.26 | 6.5 | 286 |
| YOLOv11n | 91.0 | 78.1 | 86.3 | 48.2 | 2.60 | 6.3 | 284 |
| YOLOv12n | 86.2 | 77.5 | 85.1 | 47.4 | 2.52 | 6.0 | 182 |
| REL-YOLO | 88.9 | 80.0 | 87.6 | 48.0 | 2.26 | 4.3 | 242 |
| 模型 | Precision/% | Recall/% | mAP@50/% | mAP@50:95/% | 参数量/106 | 浮点运算量/GFLOPs | 检测速度/(frame·s-1) |
|---|---|---|---|---|---|---|---|
| YOLOv8n | 86.6 | 72.6 | 83.7 | 56.2 | 3.01 | 8.1 | 305 |
| YOLOv9t | 87.7 | 72.9 | 84.0 | 57.6 | 2.00 | 7.6 | 251 |
| YOLOv10n | 83.6 | 72.9 | 82.3 | 56.4 | 2.26 | 6.5 | 286 |
| YOLOv11n | 87.3 | 72.7 | 84.0 | 56.5 | 2.60 | 6.3 | 284 |
| YOLOv12n | 83.7 | 71.7 | 82.1 | 54.1 | 2.52 | 6.0 | 182 |
| MHAF-YOLOn | 87.3 | 70.3 | 81.6 | 52.8 | 2.27 | 7.7 | 123 |
| Mamba-YOLOt | 87.9 | 74.2 | 85.2 | 59.3 | 5.98 | 13.6 | 103 |
| YOLOv5s[ | 87.7 | 75.0 | 84.8 | 57.9 | 9.11 | 23.8 | 84 |
| YOLOv8[ | 86.4 | 74.5 | 84.8 | 57.5 | 3.10 | 8.5 | 262 |
| REL-YOLO | 86.5 | 75.9 | 86.0 | 58.0 | 2.26 | 4.3 | 242 |
Tab. 4 Comparison of evaluation indicators of different models on Road waterlogging dataset
| 模型 | Precision/% | Recall/% | mAP@50/% | mAP@50:95/% | 参数量/106 | 浮点运算量/GFLOPs | 检测速度/(frame·s-1) |
|---|---|---|---|---|---|---|---|
| YOLOv8n | 86.6 | 72.6 | 83.7 | 56.2 | 3.01 | 8.1 | 305 |
| YOLOv9t | 87.7 | 72.9 | 84.0 | 57.6 | 2.00 | 7.6 | 251 |
| YOLOv10n | 83.6 | 72.9 | 82.3 | 56.4 | 2.26 | 6.5 | 286 |
| YOLOv11n | 87.3 | 72.7 | 84.0 | 56.5 | 2.60 | 6.3 | 284 |
| YOLOv12n | 83.7 | 71.7 | 82.1 | 54.1 | 2.52 | 6.0 | 182 |
| MHAF-YOLOn | 87.3 | 70.3 | 81.6 | 52.8 | 2.27 | 7.7 | 123 |
| Mamba-YOLOt | 87.9 | 74.2 | 85.2 | 59.3 | 5.98 | 13.6 | 103 |
| YOLOv5s[ | 87.7 | 75.0 | 84.8 | 57.9 | 9.11 | 23.8 | 84 |
| YOLOv8[ | 86.4 | 74.5 | 84.8 | 57.5 | 3.10 | 8.5 | 262 |
| REL-YOLO | 86.5 | 75.9 | 86.0 | 58.0 | 2.26 | 4.3 | 242 |
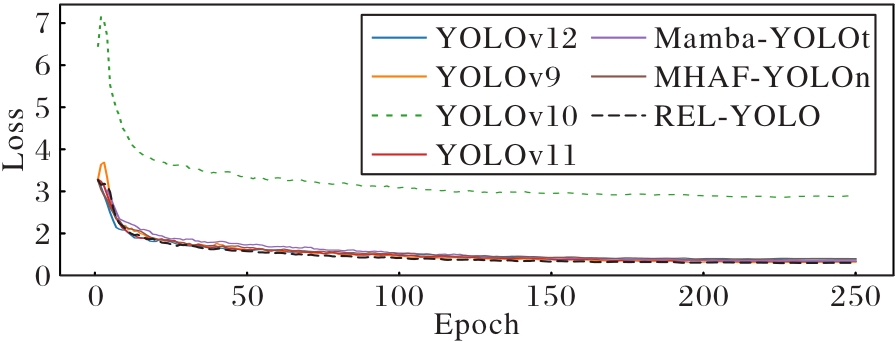
Fig. 9 Loss value variation curves
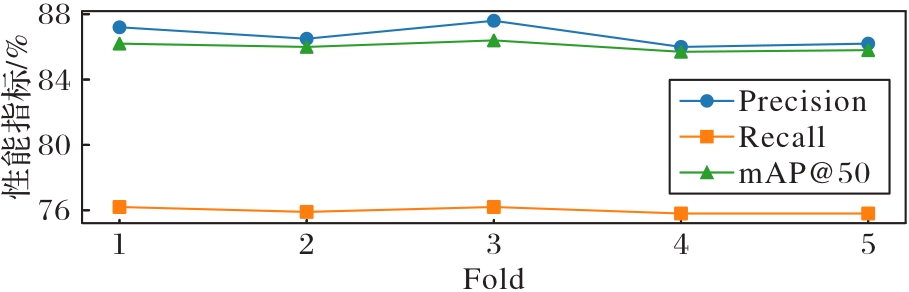
Fig. 10 Cross-validation results
| 模型 | Precision/% | Recall/% | mAP@50/% | 参数量/106 | 浮点运算量/GFLOPs |
|---|---|---|---|---|---|
| U-Net++ | 59.4 | 64.2 | 55.4 | 9.10 | 30.9 |
| DeepLabv3+ | 57.7 | 54.7 | 53.6 | 39.70 | 61.9 |
| REL-YOLO | 85.7 | 75.5 | 84.7 | 2.26 | 4.3 |
Tab. 5 Performance comparison of segmentation models on detection tasks
| 模型 | Precision/% | Recall/% | mAP@50/% | 参数量/106 | 浮点运算量/GFLOPs |
|---|---|---|---|---|---|
| U-Net++ | 59.4 | 64.2 | 55.4 | 9.10 | 30.9 |
| DeepLabv3+ | 57.7 | 54.7 | 53.6 | 39.70 | 61.9 |
| REL-YOLO | 85.7 | 75.5 | 84.7 | 2.26 | 4.3 |
| LSDECD | RAFE | C3k2_Enhanced | Precision/% | Recall/% | mAP@50/% | mAP@50:95/% | 参数量/106 |
|---|---|---|---|---|---|---|---|
| 87.3 | 72.7 | 84.0 | 56.5 | 2.60 | |||
| √ | 86.7 | 73.8 | 85.0 | 57.6 | 2.45 | ||
| √ | √ | 85.5 | 75.0 | 85.8 | 58.6 | 2.49 | |
| √ | √ | √ | 86.5 | 75.9 | 86.0 | 58.0 | 2.26 |
Tab. 6 Ablation experiment results on Road waterlogging dataset
| LSDECD | RAFE | C3k2_Enhanced | Precision/% | Recall/% | mAP@50/% | mAP@50:95/% | 参数量/106 |
|---|---|---|---|---|---|---|---|
| 87.3 | 72.7 | 84.0 | 56.5 | 2.60 | |||
| √ | 86.7 | 73.8 | 85.0 | 57.6 | 2.45 | ||
| √ | √ | 85.5 | 75.0 | 85.8 | 58.6 | 2.49 | |
| √ | √ | √ | 86.5 | 75.9 | 86.0 | 58.0 | 2.26 |
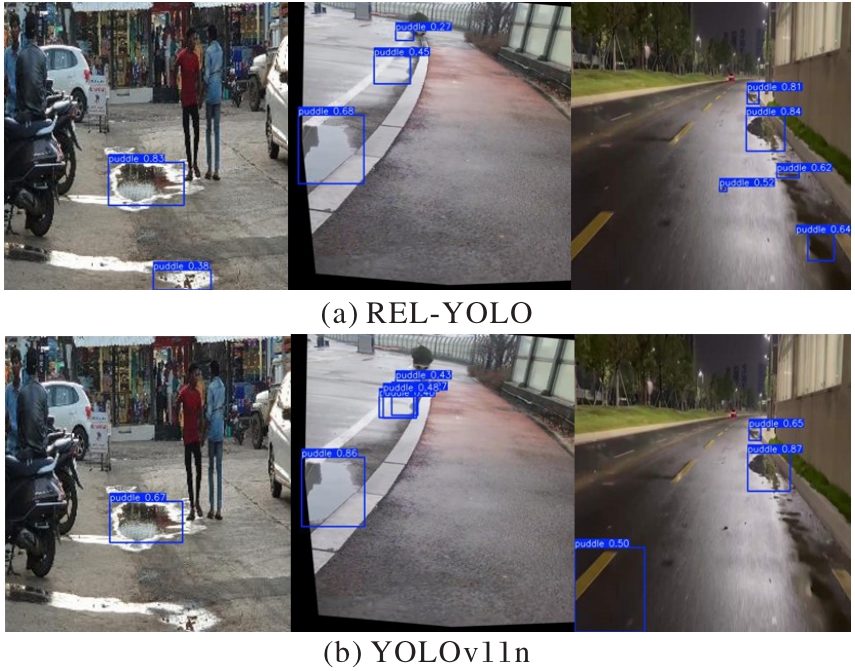
Fig. 11 Visual comparison between REL-YOLO and YOLOv11n
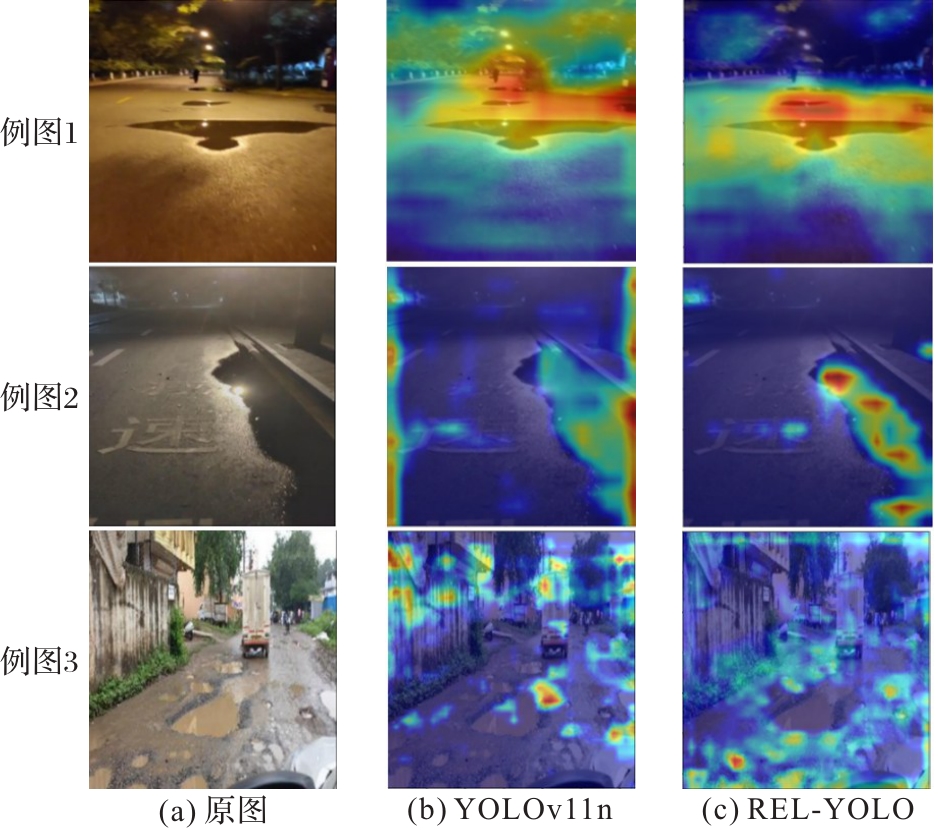
Fig. 12 Comparison of heatmaps between REL-YOLO and YOLOv11n
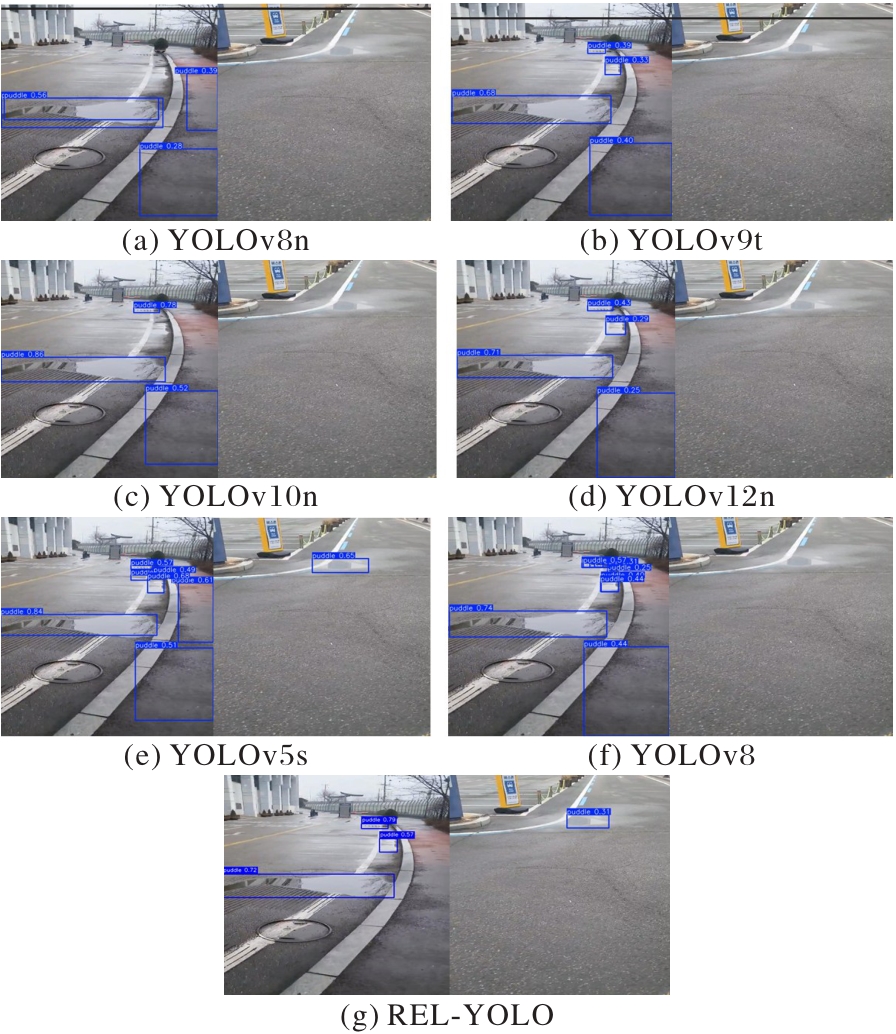
Fig. 13 Visualization results of different models
| [1] | Liu C, Nie T, Du Y, et al. A response-type road anomaly detection and evaluation method for steady driving of automated vehicles [J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(11): 21984-21995. |
| [2] | Aki M, Rojanaarpa T, Nakano K, et al. Road surface recognition using laser radar for automatic platooning [J]. IEEE Transactions on Intelligent Transportation Systems, 2016, 17(10): 2800-2810. |
| [3] | Kalliris M, Kanarachos S, Kotsakis R, et al. Machine learning algorithms for wet road surface detection using acoustic measurements [C]// ICM 2019. Piscataway: IEEE, 2019: 265-270. |
| [4] | Nakashima S, Aramaki S, Kitazono Y, et al. Application of ultrasonic sensors in road surface condition distinction methods [J]. Sensors, 2016, 16(10): No.1678. |
| [5] | Kim M H, Park J, Choi S. Road type identification ahead of the tire using D-CNN and reflected ultrasonic signals [J]. International Journal of Automotive Technology, 2021, 22(1): 47-54. |
| [6] | Shinmoto Y, Takagi J, Egawa K, et al. Road surface recognition sensor using an optical spatial filter [C]// 1997 Conference on Intelligent Transportation Systems. Piscataway: IEEE, 1997: 1000-1004. |
| [7] | Yao F, Wang C, Dong D, et al. High-resolution mapping of urban surface water using ZY-3 multi-spectral imagery [J]. Remote Sensing, 2015, 7(9): 12336-12355. |
| [8] | Kim J, Baek J, Choi H, et al. Wet area and puddle detection for Advanced Driver Assistance Systems (ADAS) using a stereo camera[J]. International Journal of Control, Automation and Systems, 2016, 14(1): 263-271. |
| [9] | Koch R, May S, Nüchter A. Detection and purging of specular reflective and transparent object influences in 3D range measurements [J]. The International Archives of the Photogrammetry, Remote Sensing and Spatial Information Sciences, 2017, XLII-2/W3: 377-384. |
| [10] | Bianconi F, Fernández A, Sánchez-Yáñez R E. Special issue texture and color in image analysis [J]. Applied Sciences, 2021, 11(9): No.3801. |
| [11] | Shibata K, Furukane T, Kawai S, et al. Distinction of wet road surface condition at night using texture features [J]. Electronics and Communications in Japan, 2014, 97(6): 51-57. |
| [12] | Amthor M, Hartmann B, Denzler J. Road condition estimation based on spatio-temporal reflection models [C]// GCPR 2015, LNCS 9358. Cham: Springer, 2015: 3-15. |
| [13] | Kawai S, Takeuchi K, Shibata K, et al. A method to distinguish road surface conditions for car-mounted camera images at night-time [C]// ITST 2012. Piscataway: IEEE, 2012: 668-672. |
| [14] | Zhang Y, Xie J, Álvarez J M, et al. Capitalizing on RGB-FIR hybrid imaging for road detection [J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(8): 13819-13834. |
| [15] | Lin C, Tian D, Duan X, et al. DA-RDD: toward domain adaptive road damage detection across different countries [J]. IEEE Transactions on Intelligent Transportation Systems, 2023, 24(3): 3091-3103. |
| [16] | Ganguly B, Dey D, Munshi S. An unsupervised learning approach for road anomaly segmentation using RGB-D sensor for advanced driver assistance system [J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(10): 19042-19053. |
| [17] | Sazara C, Cetin M, Iftekharuddin K M. Detecting floodwater on roadways from image data with handcrafted features and deep transfer learning [C]// ITSC 2019. Piscataway: IEEE, 2019: 804-809. |
| [18] | Witherow M A, Sazara C, Winter-Arboleda I M, et al. Floodwater detection on roadways from crowdsourced images [J]. Computer Methods in Biomechanics and Biomedical Engineering: Imaging and Visualization, 2019, 7: 529-540. |
| [19] | Liu J, Shang Y, Li X, et al. Road traffic waterlogging detection based on YOLOv5 [C]// IAIC 2023, CCIS 2059. Singapore: Springer, 2024: 45-58. |
| [20] | 白岗岗,侯精明,韩浩,等. 基于深度学习的道路积水智能监测方法[J]. 水资源保护, 2021, 37(5): 75-80. |
| Bai Ganggang, Hou Jingming, Han Hao, et al. Intelligent monitoring method for road inundation based on deep learning[J]. Water Resources Protection, 2021, 37(5): 75-80. | |
| [21] | Han X, Nguyen C, You S, et al. Single image water hazard detection using FCN with reflection attention units [C]// ECCV 2018, LNCS 11210. Cham: Springer, 2018: 105-121. |
| [22] | Tahara H, Ikegami I, Takakura K, et al. Puddle detection for avoidance path planning of wheeled mobile robot using laser reflection intensity [C]// IECON 2019. Piscataway: IEEE, 2019, 1: 699-704. |
| [23] | 胡昊,李擎,马鑫,等. 基于影像的道路积水监测研究[J]. 华北水利水电大学学报(自然科学版), 2023, 44(1): 62-70. |
| Hu Hao, Li Qing, Ma Xin, et al. Research on road water accumulation monitoring based on image [J]. Journal of North China University of Water Resources and Electric Power (Natural Science Edition), 2023, 44(1): 62-70. | |
| [24] | 张峥,左向阳,龙岩,等. 基于改进YOLOv8的道路积水监测方法[J]. 人民珠江, 2024, 45(10): 44-50. |
| Zhang Zheng, Zuo Xiangyang, Long Yan, et al. Monitoring method for road waterlogging based on improved YOLOv8 [J]. Pearl River, 2024, 45(10): 44-50. | |
| [25] | Huang F, Zheng J, Liu X, et al. Polarization of road target detection under complex weather conditions [J]. Scientific Reports, 2024, 14: No.30348. |
| [26] | Sheng Z, Chen F, Liu Q, et al. Real-time waterlogging monitoring on urban roads using edge computing [J]. Water Resources Management, 2025, 39(10): 5273-5287. |
| [27] | Wu Z, Zhuang C, Shi J, et al. Single-image specular highlight removal via real-world dataset construction [J]. IEEE Transactions on Multimedia, 2022, 24: 3782-3793. |
| [28] | Vignesh R, Pabitha C, Shamritha V, et al. Integrated road safety system for real-time waterlogging detection and traffic management using google maps API [C]// ICMSCI 2025. Piscataway: IEEE, 2025: 1165-1170. |
| [29] | Anwer A, Ainouz S, Saad M N M, et al. SpecSeg network for specular highlight detection and segmentation in real-world images[J]. Sensors, 2022, 22(17): No.6552. |
| [30] | Zhao J, Wang X, Zhang C, et al. Urban waterlogging monitoring and recognition in low-light scenarios using surveillance videos and deep learning [J]. Water, 2025, 17(5): No.707. |
| [31] | Liu S, Peng L, Chang X, et al. Adaptive dual-domain learning for hyperspectral anomaly detection with state space models [J]. IEEE Transactions on Geoscience and Remote Sensing, 2025, 63: No.5503719. |
| [32] | Wang C Y, Yeh I H, Mark Liao H Y. YOLOv9: learning what you want to learn using programmable gradient information [C]// ECCV 2024, LNCS 15089. Cham: Springer, 2025: 1-21. |
| [33] | Wang A, Chen H, Liu L, et al. YOLOv10: real-time end-to-end object detection [C]// NeurIPS 2024. Red Hook: Curran Associates Inc., 2024: 107984-108011. |
| [34] | Zhang R, Yang S, Lyu D, et al. AGSENet: a robust road ponding detection method for proactive traffic safety[J]. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(1): 497-516. |
| [35] | 贾军营,吴兴宇,杨海波. 基于改进DeepLabv3+的道路积水检测[J]. 计算机系统应用, 2025, 34(4): 175-183. |
| Jia Junying, Wu Xingyu, Yang Haibo. Road water accumulation detection based on improved DeepLabv3+ [J]. Computer Systems and Applications, 2025, 34(4): 175-183. | |
| [36] | Selvaraju R R, Cogswell M, Das A, et al. Grad-Cam: visual explanations from deep networks via gradient-based localization[C]// ICCV 2017. Piscataway: IEEE, 2017: 618-626. |
| [1] | Jiangyan CHEN, Yandan WANG, Yihu LIU, Yinglong MA. Collaborative query optimization-based framework for long-tailed object detection [J]. Journal of Computer Applications, 2026, 46(9): 2769-2775. |
| [2] | Dingli YANG, Yuanfang WEI, Wenrui HU, Liyang KONG, Yinshan YU. Spatio-temporal modeling and hierarchical feature enhancement for person re-identification [J]. Journal of Computer Applications, 2026, 46(9): 2776-2786. |
| [3] | Hua YAO, Gaoming YANG, Xuelian LI, Kaixuan LU. Remote sensing small object detection with dynamic perception and cross-modulation [J]. Journal of Computer Applications, 2026, 46(9): 2968-2976. |
| [4] | Cheng WANG, Zhilong LIU, Junnan DU, Wen YANG, Tianyi WANG. Foreign object detection method for transmission lines based on improved Hyper-YOLO model [J]. Journal of Computer Applications, 2026, 46(8): 2640-2651. |
| [5] | Lin HUANG, Yingshun LI, Weiyan TONG, Shuyuan ZHANG, Zihan WANG. Remote sensing image object detection algorithm based on improved real-time detection Transformer [J]. Journal of Computer Applications, 2026, 46(8): 2652-2659. |
| [6] | Li TANG, Jianyu ZHANG, Rui YAO. Object detection algorithm based on improved YOLOv11 in foggy weather [J]. Journal of Computer Applications, 2026, 46(8): 2630-2639. |
| [7] | Wenling LIU, Yong LI, Jiahui LI, Houkang ZHANG. Unsupervised dehazing method for remote sensing images with non-uniform haze [J]. Journal of Computer Applications, 2026, 46(7): 2297-2306. |
| [8] | Yi DU, Mingjin XU, Jiayi KONG, Liyao WANG, Chen ZHAO. Low-rank adaptive parameter-efficient fine-tuning algorithm based on YOLOv11 [J]. Journal of Computer Applications, 2026, 46(6): 1738-1745. |
| [9] | Qiuyan YIN, Jing DING, Zhigang NIE. YOLO-AirPose: human pose estimation algorithm in UAV aerial view [J]. Journal of Computer Applications, 2026, 46(6): 1989-1997. |
| [10] | Xiaoqin YU, Wuyang SHAN, Junying QIU, Yu LIN, Ronghao YANG, Mao TIAN. Image tampering localization and detection network under brightness-contrast disturbances [J]. Journal of Computer Applications, 2026, 46(6): 1893-1903. |
| [11] | Minqi WU, Yuanhua YANG, Hang LI, Yaqin HU, Zhihao TANG, Teng MEI. Lightweight underwater small object detection based on graph Transformer and RT-DETR [J]. Journal of Computer Applications, 2026, 46(5): 1586-1595. |
| [12] | Hongrui ZHANG, Weiming FENG, Luxia YANG, Yongjie MA. CSAF-YOLO: improved YOLO11 algorithm for underwater small object detection [J]. Journal of Computer Applications, 2026, 46(5): 1578-1585. |
| [13] | Wen PENG, Bokai ZHANG, Jinwei LIN. Chromosome cascaded classification framework integrating image texture enhancement and super-resolution [J]. Journal of Computer Applications, 2026, 46(5): 1647-1657. |
| [14] | Shuai HE, Chunhua DENG. Object detection algorithm with few-shot learning based on YOLO-World [J]. Journal of Computer Applications, 2026, 46(4): 1275-1282. |
| [15] | Peng CHEN, Xu LI, Xiaosheng YU. RGB-D dual-stream mirror network for camouflaged object detection [J]. Journal of Computer Applications, 2026, 46(4): 1253-1263. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
