


《计算机应用》唯一官方网站 ›› 2026, Vol. 46 ›› Issue (10): 3384-3390.DOI: 10.11772/j.issn.1001-9081.2025091071
• 前沿与综合应用 • 上一篇
韩涛, 韩李涛( ), 纪然
收稿日期:2025-09-17
修回日期:2025-10-30
接受日期:2025-11-04
发布日期:2025-11-10
出版日期:2026-10-10
通讯作者:
韩李涛
作者简介:韩涛(2000—),男,山东滨州人,硕士研究生,主要研究方向:室内应急疏散规划基金资助:Received:2025-09-17
Revised:2025-10-30
Accepted:2025-11-04
Online:2025-11-10
Published:2026-10-10
Contact:
Litao HAN
About author:HAN Tao, born in 2000, M. S. candidate. His research interests include indoor emergency evacuation planning.Supported by:摘要:
实时动态的最优路径规划对于室内火灾场景下的人员快速逃生至关重要。然而,由于室内火灾发展迅速且动态性强,现有疏散路径规划算法在多源多汇场景中还无法实现高效的动态路径规划。针对该问题,提出一种基于改进D*Lite算法的室内火灾应急疏散路径规划方法——矩形约束的共享环境图D*Lite(RCSM-D*Lite)。首先,引入搜索矩形约束,减少遍历节点数;其次,针对火灾场景快速扩散的特点,使用双层搜索机制确保逃生主体远离火灾危险区域;最后,引入虚拟节点统一出口并使用共享环境图实现地图、火灾危险度等火灾动态场景的信息共享,提升算法效率。在40×160的地图中进行20人路径规划实验,实验结果表明:改进D*Lite算法相较于原始D*Lite算法耗时降低了72.1%;火灾动态场景仿真结果验证了该算法能够确保行人远离火灾危险区域,安全到达出口,为室内应急疏散仿真与规划提供更好的支持。
中图分类号:
韩涛, 韩李涛, 纪然. 面向室内火灾的多源多汇实时动态路径规划方法[J]. 计算机应用, 2026, 46(10): 3384-3390.
Tao HAN, Litao HAN, Ran JI. Real-time dynamic multi-source multi-sink path planning method for indoor fire scenarios[J]. Journal of Computer Applications, 2026, 46(10): 3384-3390.
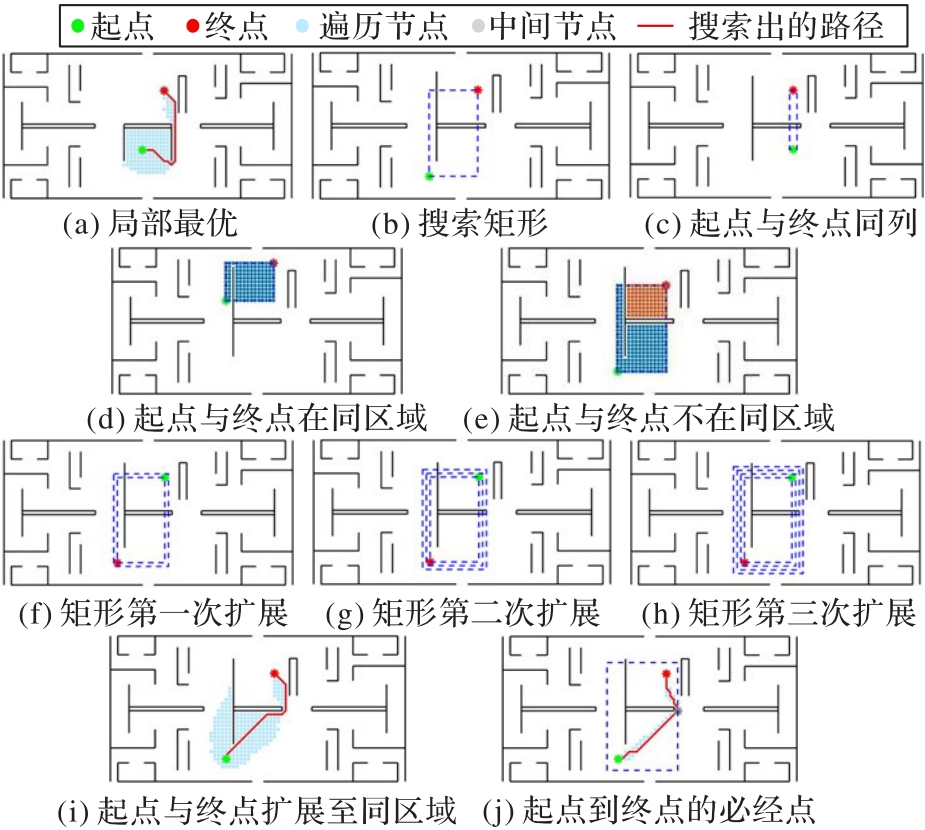
图1 搜索矩形检测机制
Fig. 1 Search rectangle detection mechanism
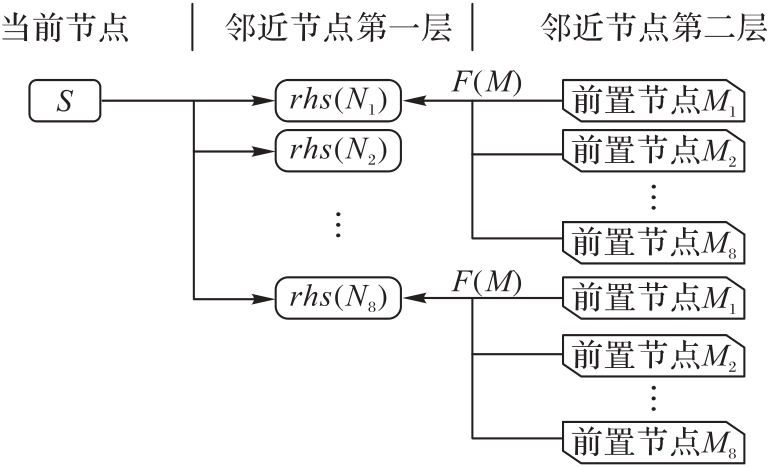
图2 双层遍历结构
Fig. 2 Dual-layer traversal structure
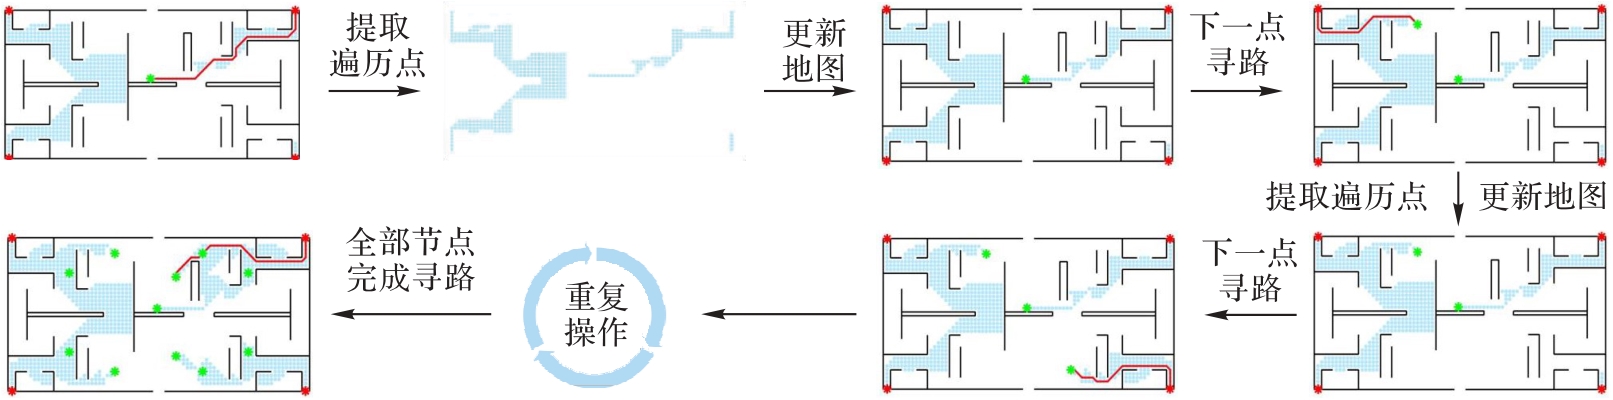
图3 共享环境图的流程
Fig. 3 Flow of sharing environment map
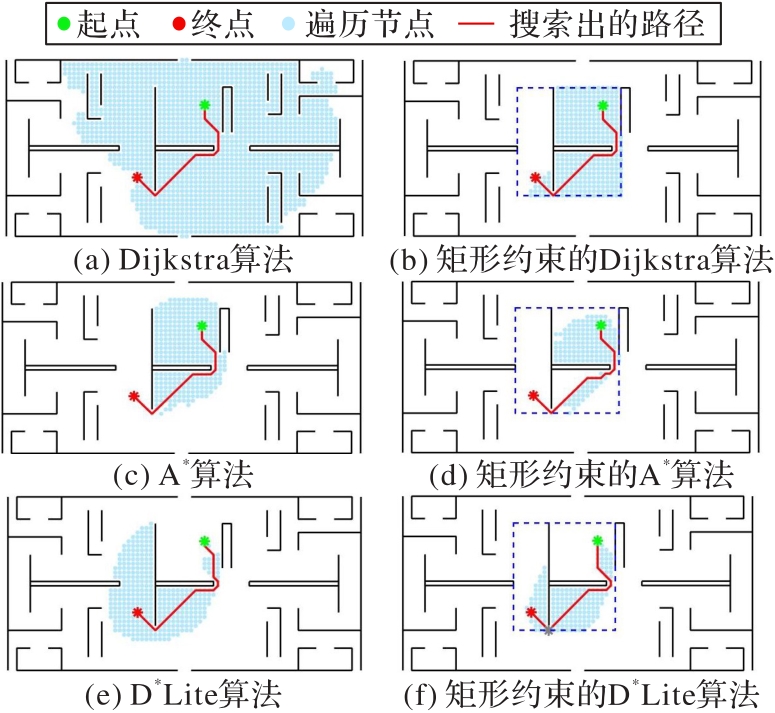
图4 不同算法的结果对比
Fig. 4 Comparison of results of different algorithms
| 算法 | 路径点数 | 路径长度 | 遍历点数 | 算法耗时/s |
|---|---|---|---|---|
| Dijkstra算法 | 29 | 35.042 | 1 623 | 0.035 |
| A*算法 | 29 | 35.042 | 322 | 0.018 |
| D*Lite算法 | 29 | 35.042 | 353 | 0.029 |
| 矩形约束的Dijkstra算法 | 29 | 35.042 | 362 | 0.018 |
| 矩形约束的A*算法 | 29 | 35.042 | 182 | 0.015 |
| 矩形约束的D*Lite算法 | 29 | 35.042 | 187 | 0.026 |
表1 不同算法的性能对比
Tab. 1 Performance comparison of different algorithms
| 算法 | 路径点数 | 路径长度 | 遍历点数 | 算法耗时/s |
|---|---|---|---|---|
| Dijkstra算法 | 29 | 35.042 | 1 623 | 0.035 |
| A*算法 | 29 | 35.042 | 322 | 0.018 |
| D*Lite算法 | 29 | 35.042 | 353 | 0.029 |
| 矩形约束的Dijkstra算法 | 29 | 35.042 | 362 | 0.018 |
| 矩形约束的A*算法 | 29 | 35.042 | 182 | 0.015 |
| 矩形约束的D*Lite算法 | 29 | 35.042 | 187 | 0.026 |
| [起点,终点] | D*Lite算法 | 矩形约束的D*Lite算法 | 双层搜索算法[ | |||
|---|---|---|---|---|---|---|
| 算法耗时/s | 遍历点数 | 算法耗时/s | 遍历点数 | 算法耗时/s | 遍历点数 | |
| 合计 | 0.104 | 2 262 | 0.075 | 1 622 | 10.909 | 12 374 |
| [(34,63),(13,58)] | 0.023 | 205 | 0.024 | 107 | 0.593 | 1 032 |
| [(7,27),(13,63)] | 0.008 | 104 | 0.006 | 91 | 0.279 | 646 |
| [(13,57),(28,71)] | 0.006 | 152 | 0.007 | 150 | 0.211 | 603 |
| [(8,70),(24,47)] | 0.004 | 129 | 0.004 | 129 | 0.552 | 888 |
| [(22,57),(19,57)] | 0.002 | 20 | 0.001 | 8 | 0.042 | 158 |
| [(31,132),(38,74)] | 0.008 | 222 | 0.008 | 212 | 0.674 | 1 289 |
| [(26,84),(34,33)] | 0.015 | 433 | 0.006 | 248 | 3.990 | 2 811 |
| [(33,117),(11,60)] | 0.021 | 450 | 0.013 | 430 | 2.021 | 1 923 |
| [(36,77),(30,32)] | 0.012 | 356 | 0.003 | 134 | 1.932 | 1 955 |
| [(8,48),(7,88)] | 0.005 | 191 | 0.003 | 113 | 0.615 | 1 069 |
表2 10组随机实验中不同算法的性能
Tab. 2 Performance of different algorithms in ten random experiments
| [起点,终点] | D*Lite算法 | 矩形约束的D*Lite算法 | 双层搜索算法[ | |||
|---|---|---|---|---|---|---|
| 算法耗时/s | 遍历点数 | 算法耗时/s | 遍历点数 | 算法耗时/s | 遍历点数 | |
| 合计 | 0.104 | 2 262 | 0.075 | 1 622 | 10.909 | 12 374 |
| [(34,63),(13,58)] | 0.023 | 205 | 0.024 | 107 | 0.593 | 1 032 |
| [(7,27),(13,63)] | 0.008 | 104 | 0.006 | 91 | 0.279 | 646 |
| [(13,57),(28,71)] | 0.006 | 152 | 0.007 | 150 | 0.211 | 603 |
| [(8,70),(24,47)] | 0.004 | 129 | 0.004 | 129 | 0.552 | 888 |
| [(22,57),(19,57)] | 0.002 | 20 | 0.001 | 8 | 0.042 | 158 |
| [(31,132),(38,74)] | 0.008 | 222 | 0.008 | 212 | 0.674 | 1 289 |
| [(26,84),(34,33)] | 0.015 | 433 | 0.006 | 248 | 3.990 | 2 811 |
| [(33,117),(11,60)] | 0.021 | 450 | 0.013 | 430 | 2.021 | 1 923 |
| [(36,77),(30,32)] | 0.012 | 356 | 0.003 | 134 | 1.932 | 1 955 |
| [(8,48),(7,88)] | 0.005 | 191 | 0.003 | 113 | 0.615 | 1 069 |
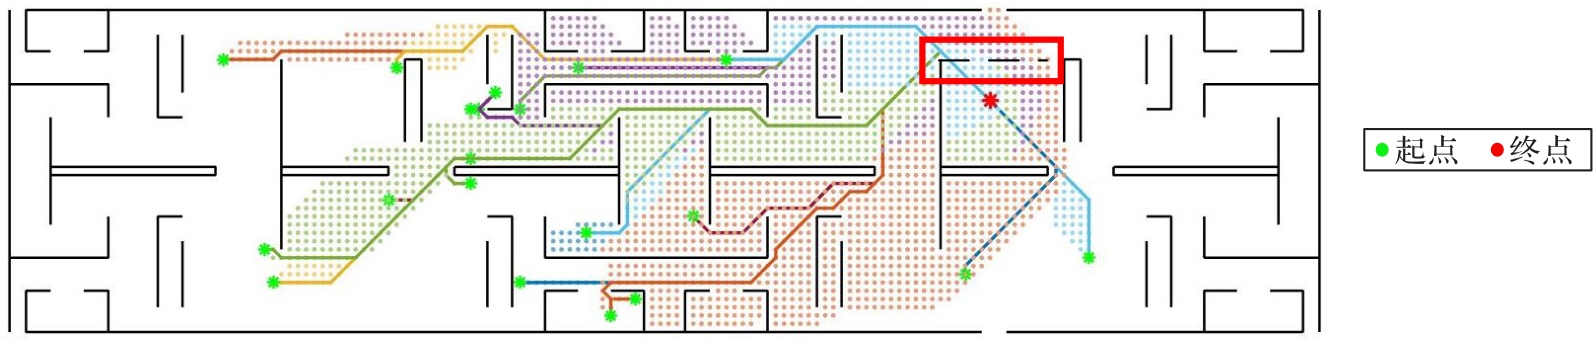
图5 20个源点的路径规划图
Fig. 5 Path planning map with twenty source points
| 算法 | 图5地图算法平均耗时/s | 对比地图算法平均耗时/s | 图5地图标准差 | 对比地图标准差 |
|---|---|---|---|---|
| D*Lite算法 | 0.481 | 0.642 | 0.016 | 0.015 |
| 矩形约束的D*Lite算法 | 0.296 | 0.478 | 0.011 | 0.018 |
| 共享环境图D*Lite算法 | 0.151 | 0.174 | 0.014 | 0.013 |
| RCSM-D*Lite算法 | 0.134 | 0.166 | 0.013 | 0.016 |
表3 不同地图下的算法性能对比
Tab. 3 Performance comparison of algorithms in different maps
| 算法 | 图5地图算法平均耗时/s | 对比地图算法平均耗时/s | 图5地图标准差 | 对比地图标准差 |
|---|---|---|---|---|
| D*Lite算法 | 0.481 | 0.642 | 0.016 | 0.015 |
| 矩形约束的D*Lite算法 | 0.296 | 0.478 | 0.011 | 0.018 |
| 共享环境图D*Lite算法 | 0.151 | 0.174 | 0.014 | 0.013 |
| RCSM-D*Lite算法 | 0.134 | 0.166 | 0.013 | 0.016 |
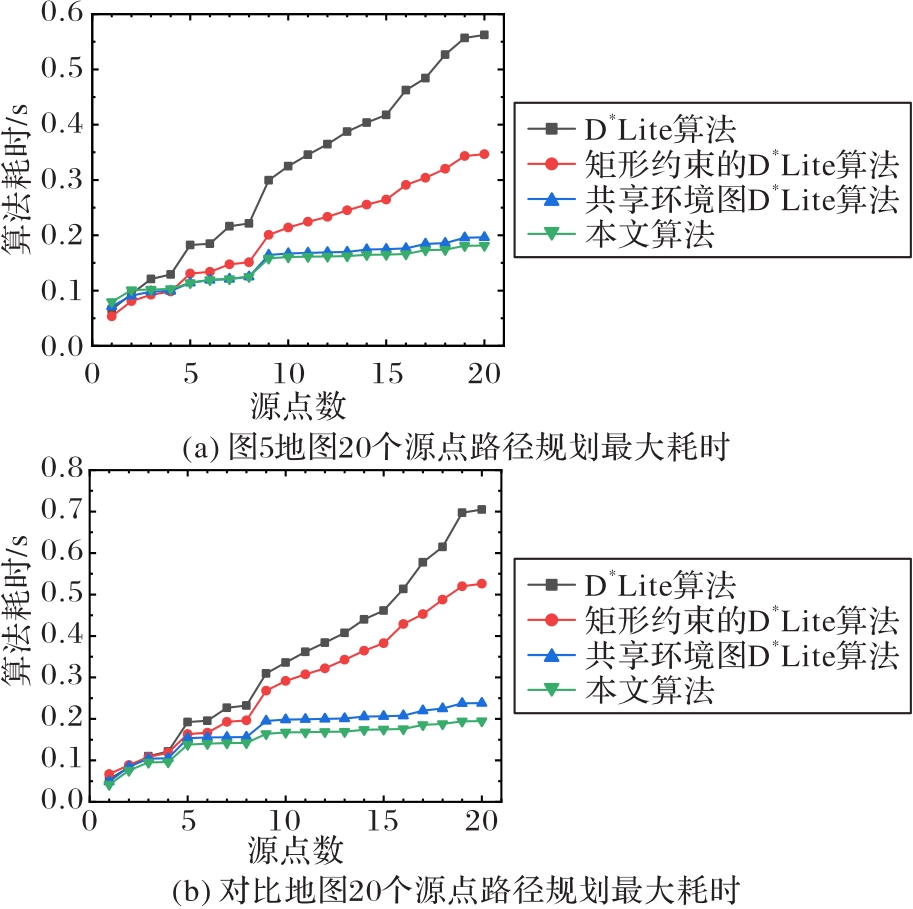
图6 不同地图中算法最大耗时对比
Fig. 6 Max running time comparison of algorithms in different maps
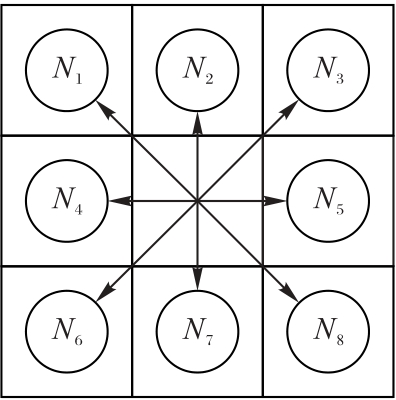
图7 8方向移动模型
Fig. 7 Eight-directional movement model
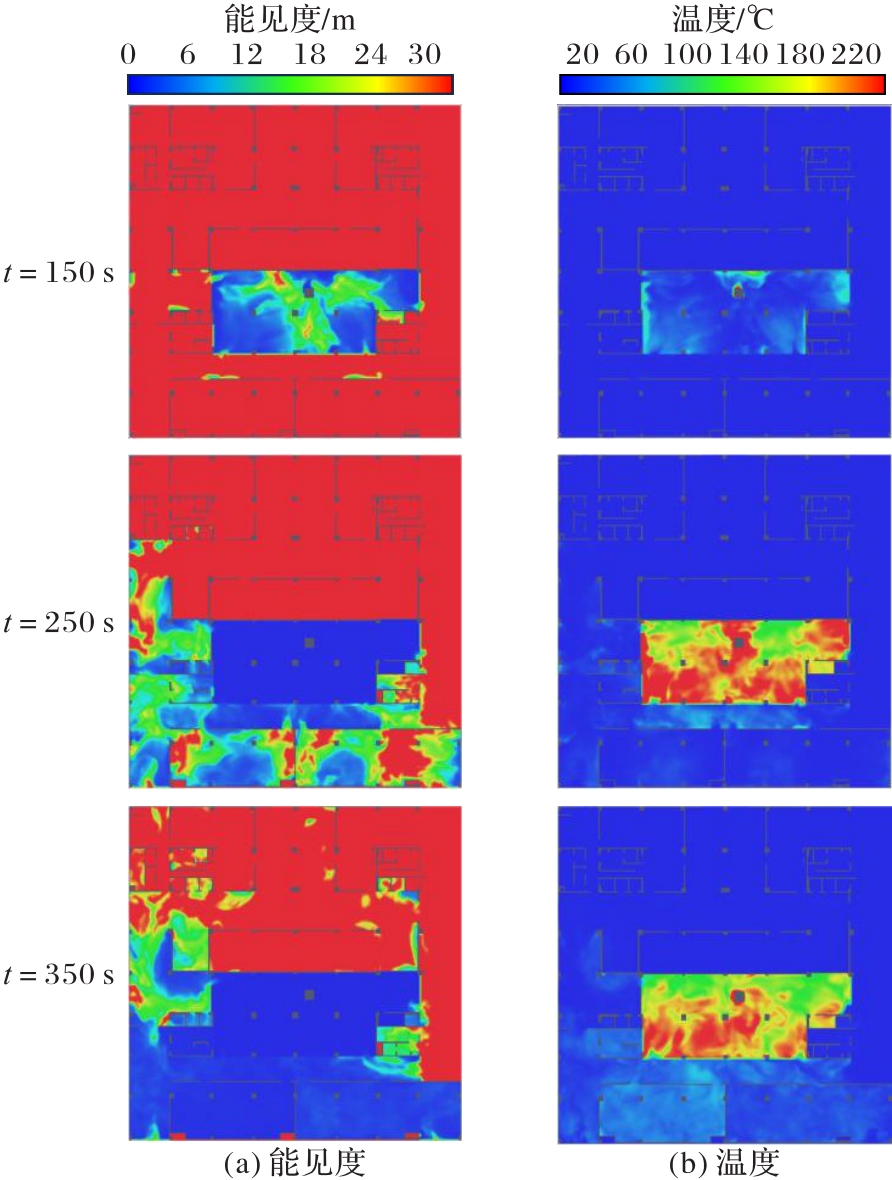
图8 火灾实验数据
Fig. 8 Experimental data of fire
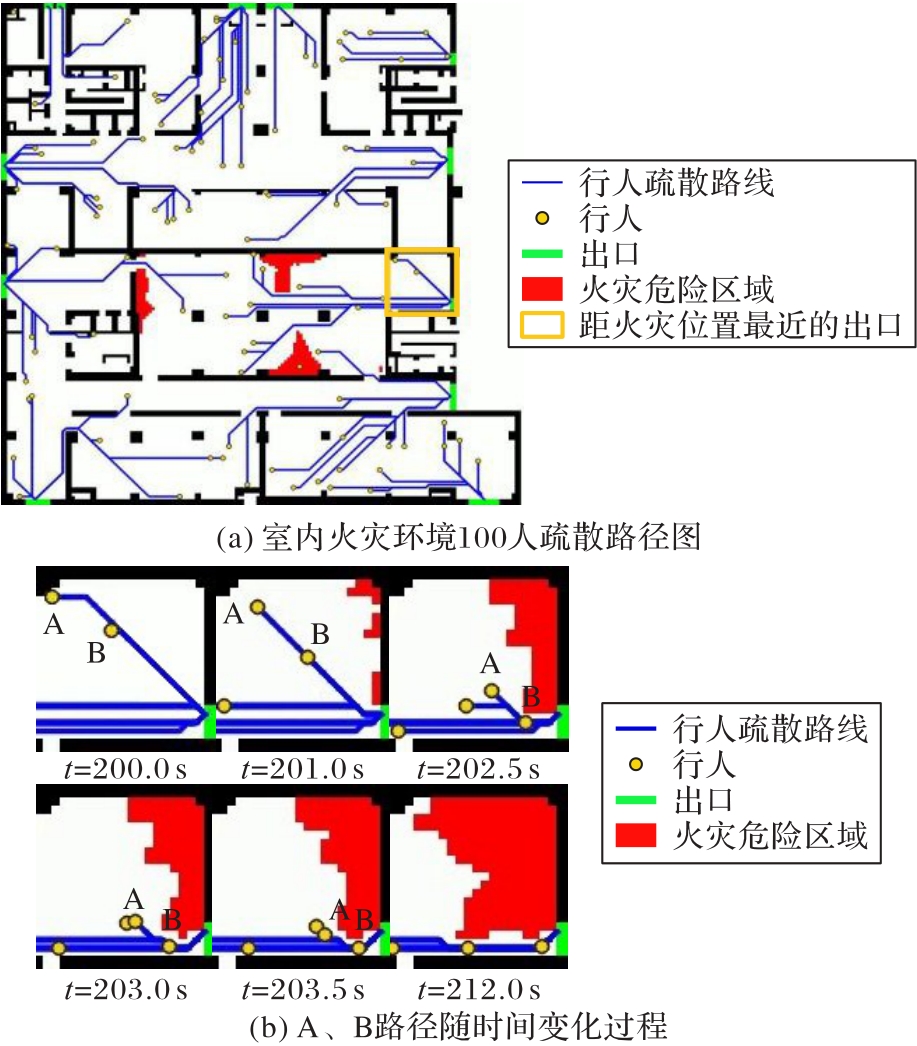
图9 行人疏散的动态路径
Fig. 9 Dynamic paths of pedestrian evacuation
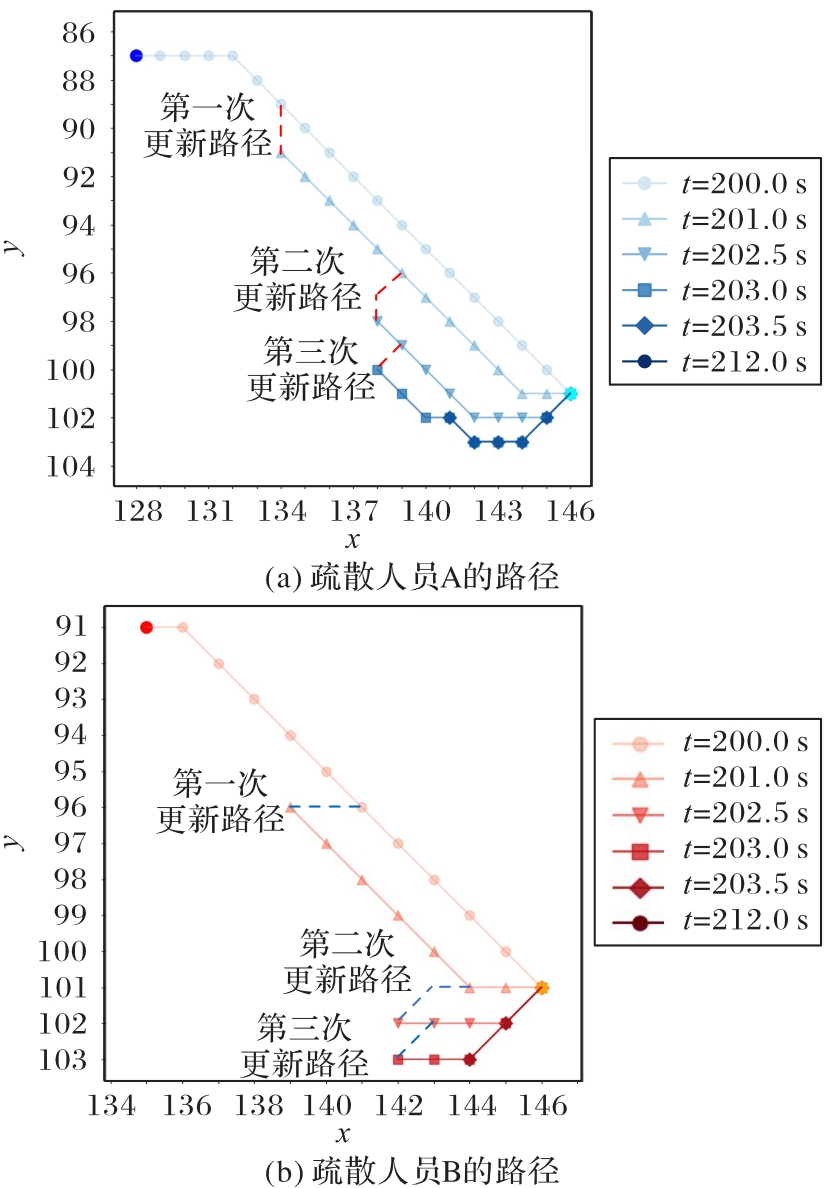
图10 疏散人员的动态路径变化对比
Fig. 10 Comparison of dynamic path changes of evacuees
| [1] | 俞凯,刘萍萍,周鲁洁. 长廊型教学楼火灾疏散模拟及对策研究[J]. 消防科学与技术, 2025, 44(3): 340-346. |
| Yu Kai, Liu Pingping, Zhou Lujie. Fire evacuation simulation and countermeasures research in a long corridor-type academic buildings[J]. Fire Science and Technology, 2025, 44(3): 340-346. | |
| [2] | Luo M, Hou X, Yang J. Surface optimal path planning using an extended Dijkstra algorithm[J]. IEEE Access, 2020, 8: 147827-147838. |
| [3] | Wang C, Wang L, Qin J, et al. Path planning of automated guided vehicles based on improved A-star algorithm[C]// ICIA 2015. Piscataway: IEEE, 2015: 2071-2076. |
| [4] | Sarbini R N, Ahmad I, Bura R O, et al. Development of pathfinding using A-star and D-star lite algorithms in video game[J]. Journal of Theoretical and Applied Information Technology, 2024, 102(3): 832-841. |
| [5] | Liu J, Yang J, Liu H, et al. An improved ant colony algorithm for robot path planning[J]. Soft Computing, 2017, 21(19): 5829-5839. |
| [6] | Lyu D, Chen Z, Cai Z, et al. Robot path planning by leveraging the graph-encoded Floyd algorithm[J]. Future Generation Computer Systems, 2021, 122: 204-208. |
| [7] | Koenig S, Likhachev M. Fast replanning for navigation in unknown terrain[J]. IEEE Transactions on Robotics, 2005, 21(3): 354-363. |
| [8] | 张华军,刘洋,朱震宇,等. 邮轮火灾动态蔓延情况下的最优疏散路径规划[J]. 中国安全科学学报, 2023, 33(1): 183-190. |
| Zhang Huajun, Liu Yang, Zhu Zhenyu, et al. Optimal evacuation path planning under dynamic spreading of cruise ship fire[J]. China Safety Science Journal, 2023, 33(1): 183-190. | |
| [9] | Han B, Qu T, Tong X, et al. Grid-optimized UAV indoor path planning algorithms in a complex environment[J]. International Journal of Applied Earth Observation and Geoinformation, 2022, 111: No.102857. |
| [10] | 蒙盾,胡卓,张华军. 基于改进A*算法的多层邮轮疏散系统仿真[J]. 系统仿真学报, 2022, 34(6): 1375-1382. |
| Meng Dun, Hu Zhuo, Zhang Huajun. Simulation of multi-layer ship evacuation system based on improved A* algorithm[J]. Journal of System Simulation, 2022, 34(6): 1375-1382. | |
| [11] | Liu Z, Liu H, Lu Z, et al. A dynamic fusion pathfinding algorithm using Delaunay triangulation and improved A-star for mobile robots[J]. IEEE Access, 2021, 9: 20602-20621. |
| [12] | Liu L, Wang B, Xu H. Research on path-planning algorithm integrating optimization A-star algorithm and artificial potential field method[J]. Electronics, 2022, 11(22): No.3660. |
| [13] | Ferguson D, Stentz A. The delayed D* algorithm for efficient path replanning[C]// ICRA 2005. Piscataway: IEEE, 2005: 2045-2050. |
| [14] | 李墨潇,张建辉,王晟旻,等. 基于改进D*Lite算法的疏散路径规划方法研究[J]. 中国安全生产科学技术, 2025, 21(3): 42-49. |
| Li Moxiao, Zhang Jianhui, Wang Shengmin, et al. Research on evacuation path planning method based on improved D*Lite algorithm[J]. Journal of Safety Science and Technology, 2025, 21(3): 42-49. | |
| [15] | 刘毅,沈斐敏. 考虑灾害实时扩散的室内火灾疏散路径选择模型[J]. 控制与决策, 2018, 33(9): 1598-1604. |
| Liu Yi, Shen Feimin. Route selection model in indoor evacuation under real effect of fire spread[J]. Control and Decision, 2018, 33(9): 1598-1604. | |
| [16] | 刘军,冯硕,任建华. 移动机器人路径动态规划有向D*算法[J]. 浙江大学学报(工学版), 2020, 54(2): 291-300. |
| Liu Jun, Feng Shuo, Ren Jianhua. Directed D* algorithm for dynamic path planning of mobile robots[J]. Journal of Zhejiang University (Engineering Science), 2020, 54(2): 291-300. | |
| [17] | 鞠慕涵,刘万科,胡捷,等. 改进D*算法的未知场景机器人运动规划[J]. 导航定位学报, 2024, 12(3): 145-153. |
| Ju Muhan, Liu Wanke, Hu Jie, et al. Motion planning for robots in unknown scenes based on improved D* algorithm[J]. Journal of Navigation and Positioning, 2024, 12(3): 145-153. | |
| [18] | LaValle S M. Rapidly-exploring random trees: a new tool for path planning[R/OL]. [2025-07-17].. |
| [19] | 陈小龙,李明智,汪雅琴,等. 基于人工势场法改进RRT*算法的无人船路径规划[J]. 舰船科学技术, 2026, 48(5): 151-157. |
| Chen Xiaolong, Li Mingzhi, Wang Yaqin, et al. Unmanned ship path planning based on the improved RRT* algorithm of artificial potential field method[J]. Ship Science and Technology, 2026, 48(5): 151-157. | |
| [20] | Xu T, Ma J, Qin P, et al. An improved RRT* algorithm based on adaptive informed sample strategy for coastal ship path planning[J]. Ocean Engineering, 2025, 333: No.121511. |
| [21] | 韩李涛,郭欢,张海思. 一种多出口室内应急疏散路径规划算法[J]. 测绘科学, 2018, 43(12): 105-110. |
| Han Litao, Guo Huan, Zhang Haisi. An algorithm for route planning applied in multi-exit indoor emergency evacuation[J]. Science of Surveying and Mapping, 2018, 43(12): 105-110. | |
| [22] | 钟委,霍然,史聪灵. 热释放速率设定方式的几点讨论[J]. 自然灾害学报, 2004, 13(2): 64-69. |
| Zhong Wei, Huo Ran, Shi Congling. Some discussion on methodology to design heat release rate[J]. Journal of Natural Disasters, 2004, 13(2): 64-69. | |
| [23] | 李明海,兰亚乐,马骁,等. 建筑火灾全局动态疏散路径规划研究[J]. 安全与环境学报, 2025, 25(1): 205-215. |
| Li Minghai, Lan Yale, Ma Xiao, et al. Research on global dynamic path planning for evacuation during building fires[J]. Journal of Safety and Environment, 2025, 25(1): 205-215. | |
| [24] | 倪凌佳,黄晓霞,李红旮,等. 基于协作式深度强化学习的火灾应急疏散仿真研究[J]. 系统仿真学报, 2022, 34(6): 1353-1366. |
| Ni Lingjia, Huang Xiaoxia, Li Hongga, et al. Research on fire emergency evacuation simulation based on cooperative deep reinforcement learning[J]. Journal of System Simulation, 2022, 34(6): 1353-1366. | |
| [25] | 谢玮,张玉春. 能见度对个体疏散速度及路径选择的影响研究[J]. 中国安全生产科学技术, 2017, 13(7): 62-67. |
| Xie Wei, Zhang Yuchun. Experimental study on impact of visibility on individual evacuation speed and path selection[J]. Journal of Safety Science and Technology, 2017, 13(7): 62-67. |
| [1] | 薛婧颖, 况立群, 王智巽, 郭正涛, 韩慧妍. 分层自适应隐式分位数的多智能体路径规划[J]. 《计算机应用》唯一官方网站, 2026, 46(8): 2533-2540. |
| [2] | 周璐辉, 岳雪芝. 混合粒子群优化算法求解带时间窗的车辆路径规划问题[J]. 《计算机应用》唯一官方网站, 2026, 46(1): 181-187. |
| [3] | 罗蒙, 高超, 王震. 基于带约束谱聚类的启发式车辆路径规划算法优化方法[J]. 《计算机应用》唯一官方网站, 2025, 45(5): 1387-1394. |
| [4] | 王兴旺, 张清杨, 姜守勇, 董永权. 基于改进鲸鱼优化算法的动态无人机路径规划[J]. 《计算机应用》唯一官方网站, 2025, 45(3): 928-936. |
| [5] | 吴素谦, 闫建国, 杨斌, 覃涛, 刘影, 杨靖. 多策略改进的天鹰优化器及其在路径规划中的应用[J]. 《计算机应用》唯一官方网站, 2025, 45(3): 937-945. |
| [6] | 王蔡琪, 崔西宁, 熊毅, 伍世虔. 基于节点到障碍物距离的自适应扩展RRT*路径规划算法[J]. 《计算机应用》唯一官方网站, 2025, 45(3): 920-927. |
| [7] | 王昱, 赵明月, 周小琳. 养老院场景下基于任务的辅助机器人路径规划[J]. 《计算机应用》唯一官方网站, 2025, 45(10): 3270-3276. |
| [8] | 冉义, 李永胜, 蒋烨. 基于S型生长曲线的蝗虫优化算法求解机器人路径规划问题[J]. 《计算机应用》唯一官方网站, 2025, 45(1): 178-185. |
| [9] | 马天, 席润韬, 吕佳豪, 曾奕杰, 杨嘉怡, 张杰慧. 基于深度强化学习的移动机器人三维路径规划方法[J]. 《计算机应用》唯一官方网站, 2024, 44(7): 2055-2064. |
| [10] | 田润泽, 周宇龙, 朱洪, 薛岗. 基于局部信息的服务迁移路径选择算法[J]. 《计算机应用》唯一官方网站, 2024, 44(7): 2168-2174. |
| [11] | 李建强, 何舟. 面向多行程取送货车辆路径问题的混合NSGA-Ⅱ[J]. 《计算机应用》唯一官方网站, 2024, 44(4): 1187-1194. |
| [12] | 黄海新, 于广威, 程寿山, 李春明. 基于改进灰狼优化的桥梁检测爬壁机器人全覆盖路径规划[J]. 《计算机应用》唯一官方网站, 2024, 44(3): 966-971. |
| [13] | 宋紫阳, 李军怀, 王怀军, 苏鑫, 于蕾. 基于路径模仿和SAC强化学习的机械臂路径规划算法[J]. 《计算机应用》唯一官方网站, 2024, 44(2): 439-444. |
| [14] | 邓辅秦, 官桧锋, 谭朝恩, 付兰慧, 王宏民, 林天麟, 张建民. 基于请求与应答通信机制和局部注意力机制的多机器人强化学习路径规划方法[J]. 《计算机应用》唯一官方网站, 2024, 44(2): 432-438. |
| [15] | 邓辅秦, 谭朝恩, 黎俊炜, 钟家铭, 付兰慧, 张建民, 王宏民, 李楠楠, 姜炳春, 林天麟. 面向大型仓储环境的基于冲突搜索算法[J]. 《计算机应用》唯一官方网站, 2024, 44(12): 3854-3860. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||
