


Journal of Computer Applications ›› 2026, Vol. 46 ›› Issue (9): 2910-2919.DOI: 10.11772/j.issn.1001-9081.2025080966
• Advanced computing • Previous Articles
Chenyang WANG1,2,3, Xiaoyu SHI2,3( ), Jie GAN2,3, Mingsheng SHANG2,3
Received:2025-08-26
Revised:2025-10-10
Accepted:2025-10-20
Online:2026-09-16
Published:2026-09-10
Contact:
Xiaoyu SHI
About author:WANG Chenyang, born in 2000, M. S. candidate. His research interests include edge computing, reinforcement learning.Supported by:
王晨阳1,2,3, 史晓雨2,3(), 甘捷2,3, 尚明生2,3
通讯作者:
史晓雨
作者简介:王晨阳(2000—),男,河南三门峡人,硕士研究生,主要研究方向:边缘计算、强化学习基金资助:CLC Number:
Chenyang WANG, Xiaoyu SHI, Jie GAN, Mingsheng SHANG. Trajectory-aware multi-agent cooperative task offloading method for vehicular edge computing[J]. Journal of Computer Applications, 2026, 46(9): 2910-2919.
王晨阳, 史晓雨, 甘捷, 尚明生. 用于车辆边缘计算的轨迹感知多智能体协同任务卸载方法[J]. 《计算机应用》唯一官方网站, 2026, 46(9): 2910-2919.
Add to citation manager EndNote|Ris|BibTeX
URL: https://www.joca.cn/EN/10.11772/j.issn.1001-9081.2025080966
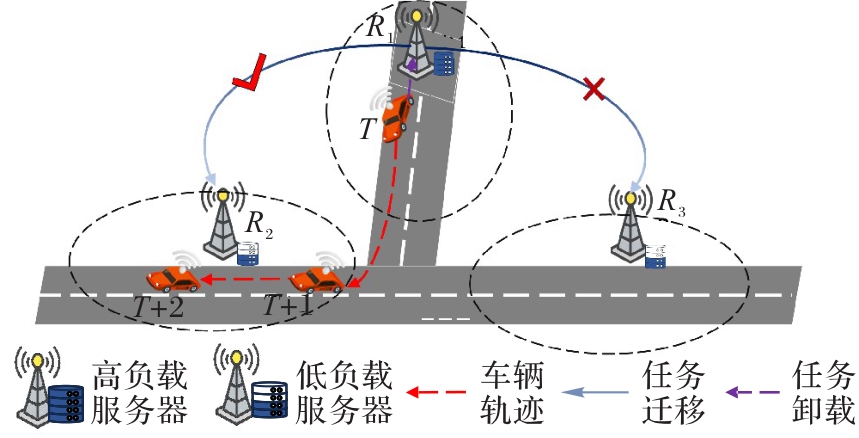
Fig. 1 Schematic diagram of collaboration issue between migration direction and vehicle trajectory
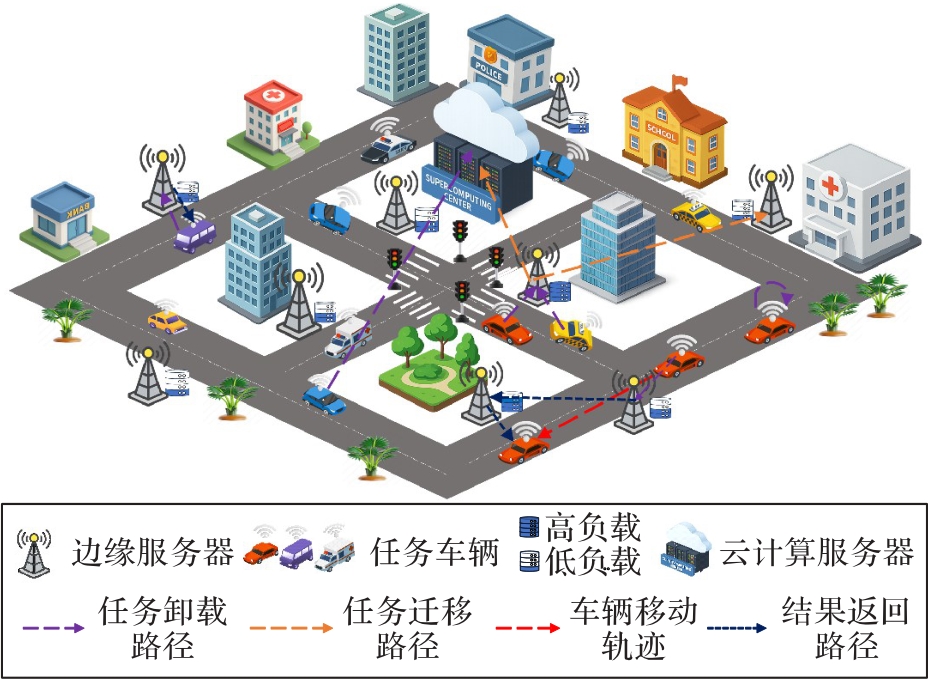
Fig. 2 VEC collaborative scenario
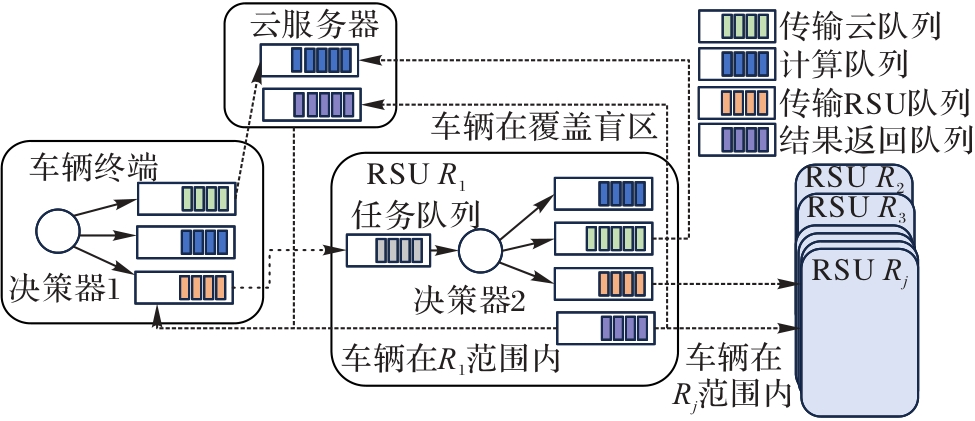
Fig. 3 Task queue model
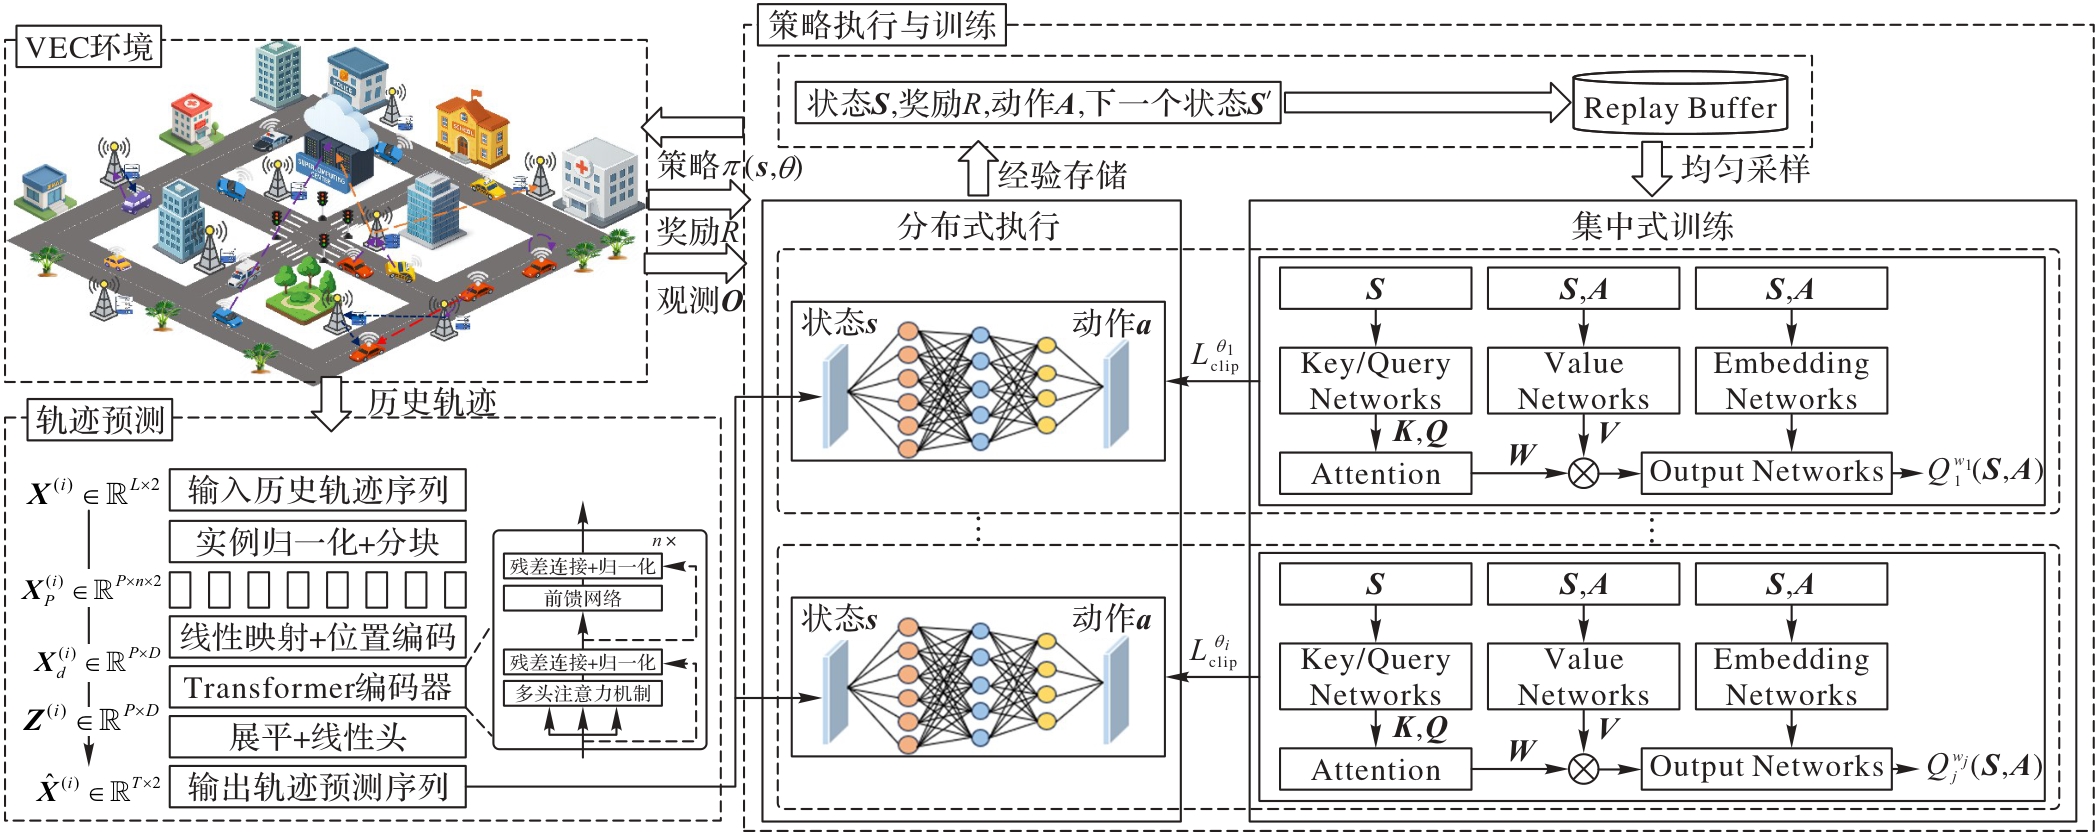
Fig. 4 Framework of TAC-MARL algorithm
| 参数 | 值 | 参数 | 值 |
|---|---|---|---|
| 60 Mbit/s | 7~10 G CPU cycles/s | ||
| 100 Mbit/s | 48~60 G CPU cycles/s | ||
| 40 Mbit/s | 200 G CPU cycles/s | ||
| 80 Mbit/s | RSU_Cover | 200 m | |
| 4~8 MB | 0.4~0.8 MB | ||
| 22 ~26 G CPU cycles | 7~12 s | ||
| 12 | 9 |
Tab. 1 Experimental parameter setting in simulation scenario
| 参数 | 值 | 参数 | 值 |
|---|---|---|---|
| 60 Mbit/s | 7~10 G CPU cycles/s | ||
| 100 Mbit/s | 48~60 G CPU cycles/s | ||
| 40 Mbit/s | 200 G CPU cycles/s | ||
| 80 Mbit/s | RSU_Cover | 200 m | |
| 4~8 MB | 0.4~0.8 MB | ||
| 22 ~26 G CPU cycles | 7~12 s | ||
| 12 | 9 |
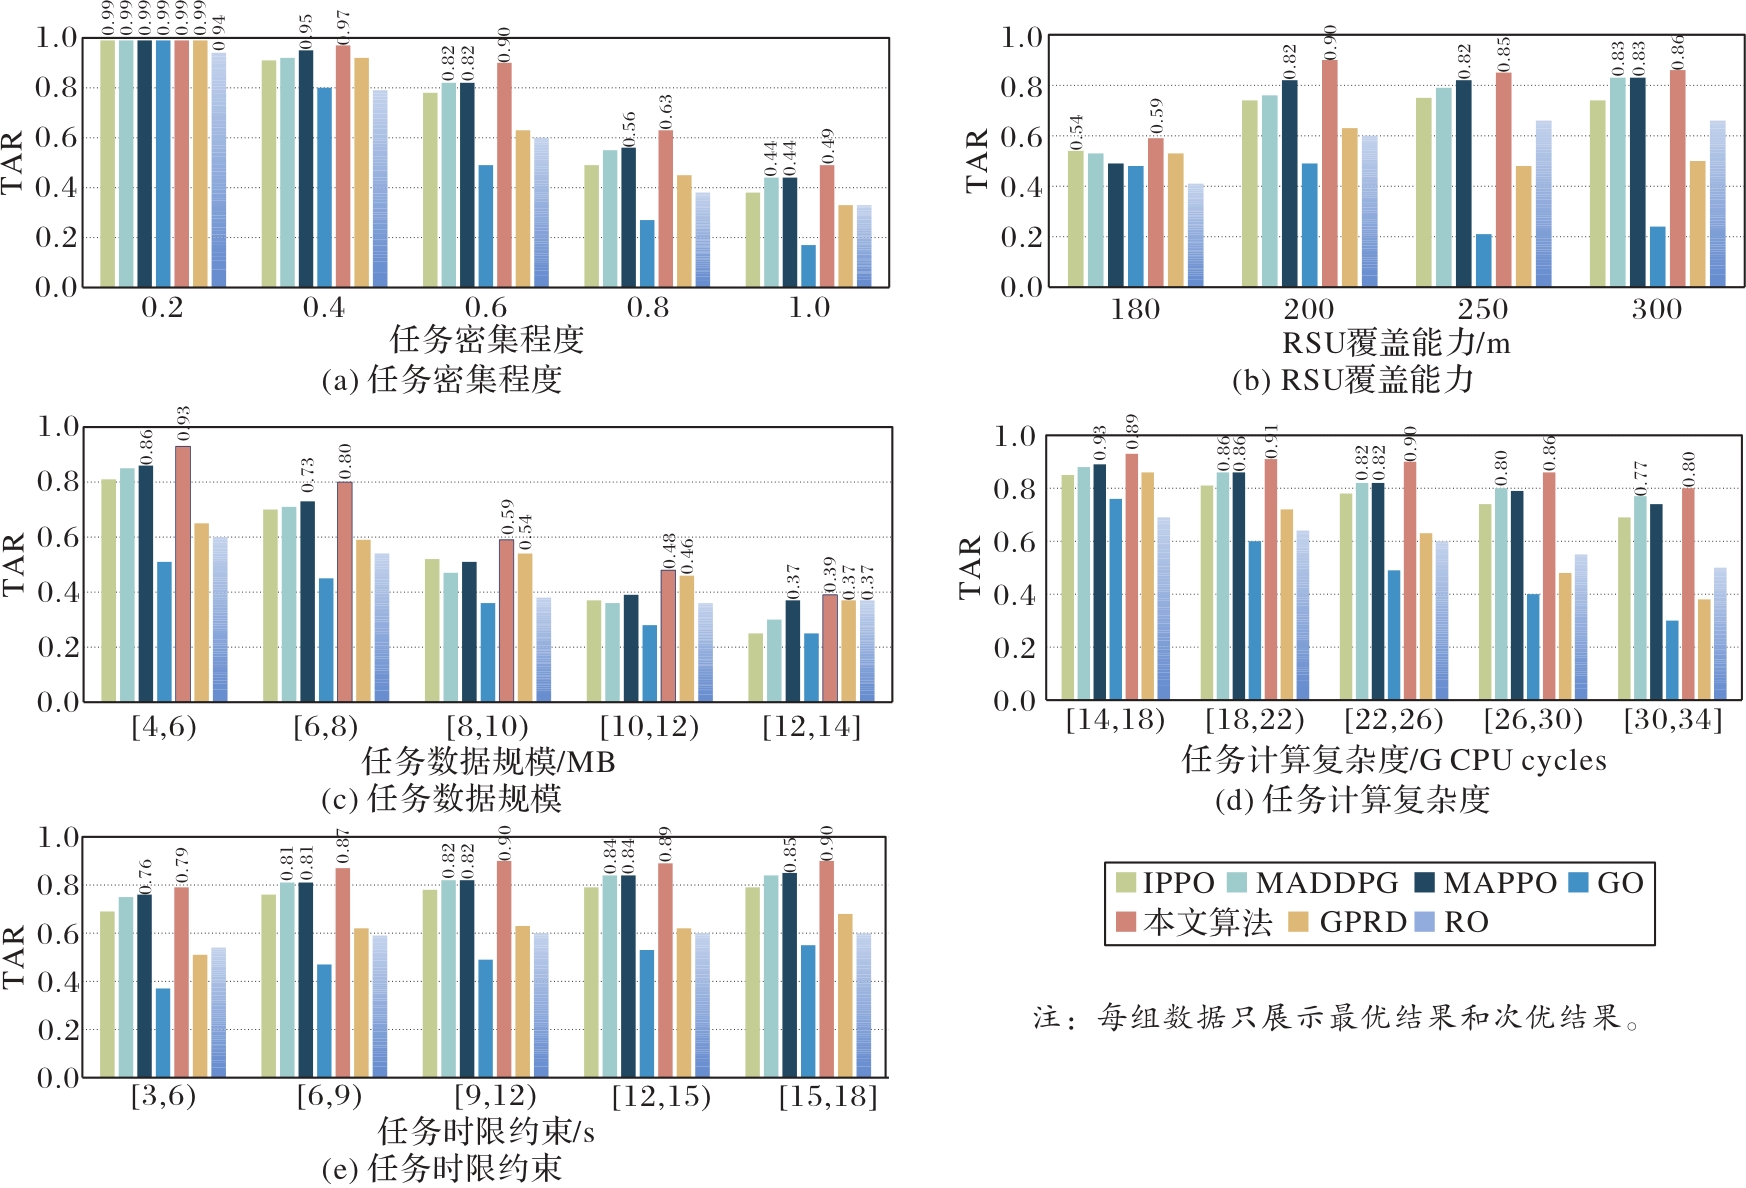
Fig. 5 TAR performance of different algorithms under varying scenario settings
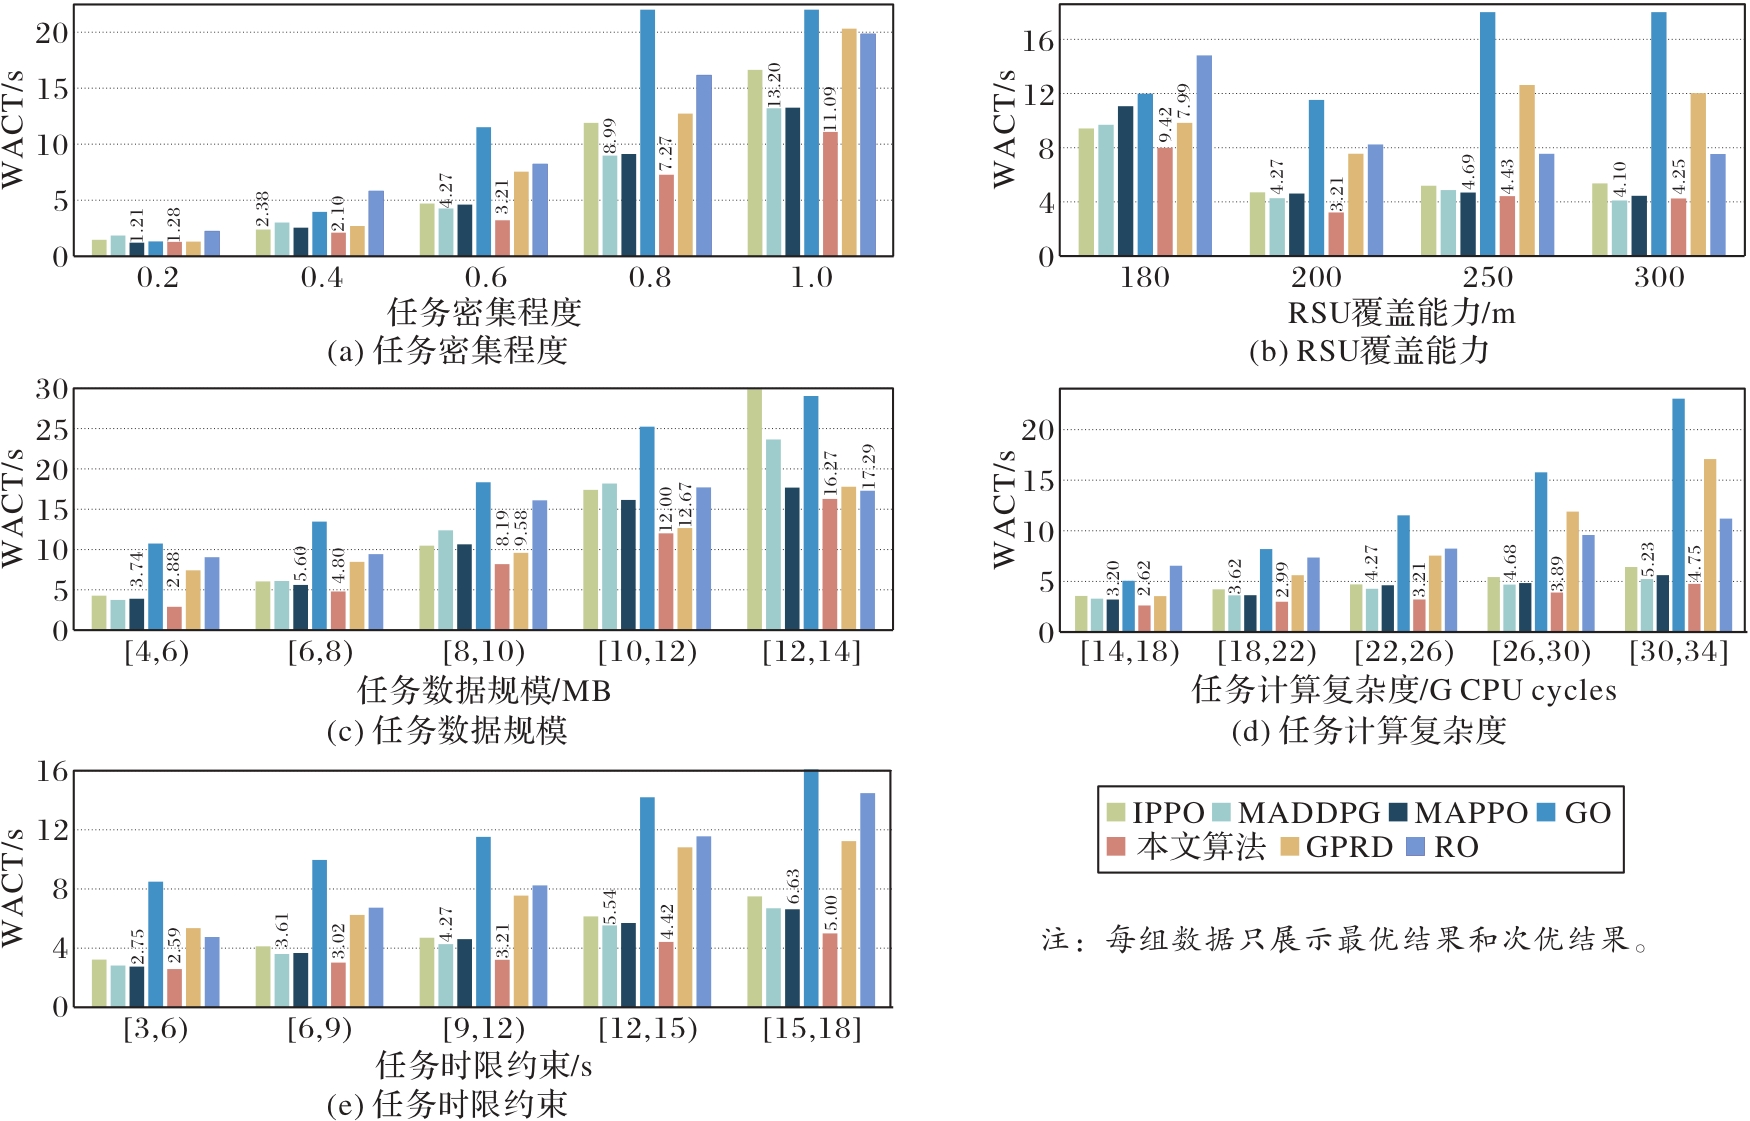
Fig. 6 WACT performance of different algorithms under varying scenario settings
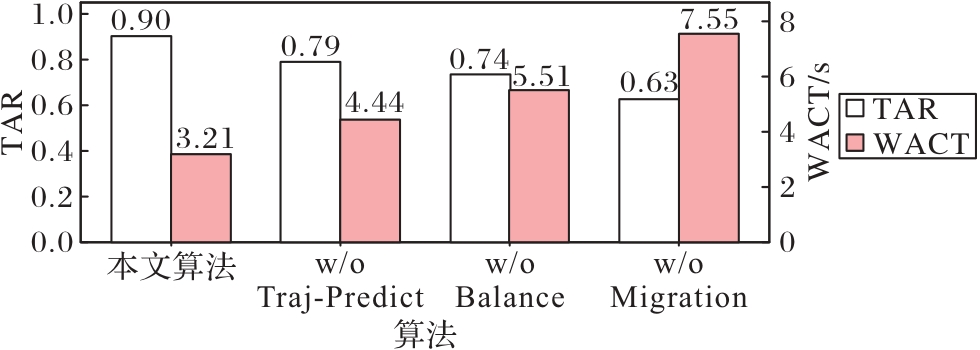
Fig. 7 Ablation experiment results
| [1] | 李智勇,王琦,陈一凡,等. 车辆边缘计算环境下任务卸载研究综述[J]. 计算机学报, 2021, 44(5): 963-982. |
| Li Zhiyong, Wang Qi, Chen Yifan, et al. A survey on task offloading research in vehicular edge computing [J]. Chinese Journal of Computers, 2021, 44(5): 963-982. | |
| [2] | Guo J, Zhou H, Zhao L, et al. Incentive-driven and SAC-based resource allocation and offloading strategy in vehicular edge computing networks [C]// IEEE INFOCOM WKSHPS 2023. Piscataway: IEEE, 2023: 1-6. |
| [3] | Shi J, Du J, Wang J, et al. Distributed V2V computation offloading based on dynamic pricing using deep reinforcement learning [C]// WCNC 2020. Piscataway: IEEE, 2020: 1-6. |
| [4] | Guo H, Rui L L, Gao Z P. V2V task offloading algorithm with LSTM-based spatiotemporal trajectory prediction model in SVCNs[J]. IEEE Transactions on Vehicular Technology, 2022, 71(10): 11017-11032. |
| [5] | Liu Z, Du H, Lin J, et al. DNN partitioning, task offloading, and resource allocation in dynamic vehicular networks: a Lyapunov-guided diffusion-based reinforcement learning approach [J]. IEEE Transactions on Mobile Computing, 2025, 24(3): 1945-1962. |
| [6] | Fan W, Zhang Y, Zhou G, et al. Deep reinforcement learning-based task offloading for vehicular edge computing with flexible RSU-RSU cooperation [J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(7): 7712-7725. |
| [7] | Pliatsios D, Sarigiannidis P, Lagkas T D, et al. Joint wireless resource and computation offloading optimization for energy efficient internet of vehicles [J]. IEEE Transactions on Green Communications and Networking, 2022, 6(3): 1468-1480. |
| [8] | Yang K, Sun P, Lin J, et al. A novel distributed task scheduling framework for supporting vehicular edge intelligence [C]// ICDCS 2022. Piscataway: IEEE, 2022: 972-982. |
| [9] | Zheng Y, Zhou H, Chen R, et al. Sac-based computation offloading and resource allocation in vehicular edge computing [C]// IEEE INFOCOM WKSHPS 2022. Piscataway: IEEE, 2022: 1-6. |
| [10] | Dai P, Huang Y, Hu K, et al. Meta reinforcement learning for multi-task offloading in vehicular edge computing [J]. IEEE Transactions on Mobile Computing, 2024, 23(3): 2123-2138. |
| [11] | Chen L, Wu J, Zhang J, et al. Dependency-aware computation offloading for mobile edge computing with edge-cloud cooperation[J]. IEEE Transactions on Cloud Computing, 2022, 10(4): 2451-2468. |
| [12] | Geng J, Qin Z, Jin S. Dynamic resource allocation for cloud-edge collaboration offloading in VEC networks with diverse tasks [J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(12): 21235-21251. |
| [13] | Dai P, Hu K, Wu X, et al. A probabilistic approach for cooperative computation offloading in MEC-assisted vehicular networks [J]. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(2): 899-911. |
| [14] | Nie Y, Nguyen N H, Sinthong P, et al. A time series is worth 64 words: long-term forecasting with Transformers[PP/OL]. V2. arXiv (2023-03-05) [2025-10-13].. |
| [15] | Zhang X, Wang C, Zhu Y, et al. Multi-agent deep reinforcement learning with trajectory prediction for task migration-assisted computation offloading [J]. IEEE Transactions on Mobile Computing, 2025, 24(7): 5839-5856. |
| [16] | Zhao L, Dong X, Hawbani A, et al. Optimizing task offloading in VEC: a PDQKM scheme combining deep reinforcement learning and Kuhn-Munkres matching [J]. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(1): 1319-1334. |
| [17] | Ho T M, Nguyen K K. Joint server selection, cooperative offloading and handover in multi-access edge computing wireless network: a deep reinforcement learning approach [J]. IEEE Transactions on Mobile Computing, 2022, 21(7): 2421-2435. |
| [18] | Ye H, Li G Y, Juang B H F. Deep reinforcement learning based resource allocation for V2V communications [J]. IEEE Transactions on Vehicular Technology, 2019, 68(4): 3163-3173. |
| [19] | Peng H, Shen X. Multi-agent reinforcement learning based resource management in MEC- and UAV-assisted vehicular networks [J]. IEEE Journal on Selected Areas in Communications, 2021, 39(1): 131-141. |
| [20] | Lowe R, Wu Y, Tamar A, et al. Multi-agent actor-critic for mixed cooperative-competitive environments [C]// NeurIPS 2017. Red Hook: Curran Associates Inc., 2017: 6382-6393. |
| [21] | Huang X, Chen Y, Liu Z, et al. Task offloading based on the fusion of model-and data-driven intelligence for vehicular edge computing networks [J]. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(6): 8525-8540. |
| [22] | Zhao L, Zhang E, Wan S, et al. MESON: a mobility-aware dependent task offloading scheme for urban vehicular edge computing [J]. IEEE Transactions on Mobile Computing, 2024, 23(5): 4259-4272. |
| [23] | Huang H, Zhan W, Min G, et al. Mobility-aware computation offloading with load balancing in smart city networks using MEC federation [J]. IEEE Transactions on Mobile Computing, 2024, 23(11): 10411-10428. |
| [24] | Zhao W, Gao P, Hong X, et al. PPO based task offloading with EKF for position prediction in RSU-assisted IoV [J]. IEEE Transactions on Cognitive Communications and Networking, 2025, 12: 703-713. |
| [25] | Liu J, Wang S, Wang J, et al. A task oriented computation offloading algorithm for intelligent vehicle network with mobile edge computing [J]. IEEE Access, 2019, 7: 180491-180502. |
| [26] | Xu C, Zhan C, Liao J, et al. Computation throughput maximization for UAV-enabled MEC with binary computation offloading [C]// ICC 2022. Piscataway: IEEE, 2022: 4348-4353. |
| [27] | Du J, Kong Z, Sun A, et al. MADDPG-based joint service placement and task offloading in MEC empowered air-ground integrated networks [J]. IEEE Internet of Things Journal, 2024, 11(6): 10600-10615. |
| [28] | Yu C, Velu A, Vinitsky E, et al. The surprising effectiveness of PPO in cooperative multi-agent games [C]// NeurIPS 2022. Red Hook: Curran Associates Inc., 2022: 24611-24624. |
| [29] | Kapoor A, Freed B, Schneider J, et al. Assigning credit with partial reward decoupling in multi-agent proximal policy optimization[PP/OL]. V3. arXiv (2025-02-07) [2025-10-12].. |
| [30] | da Costa J B D, de Souza A M, Meneguette R I, et al. Mobility and deadline-aware task scheduling mechanism for vehicular edge computing [J]. IEEE Transactions on Intelligent Transportation Systems, 2023, 24(10): 11345-11359. |
| [31] | Schulman J, Wolski F, Dhariwal P, et al. Proximal policy optimization algorithms [PP/OL]. V2. arXiv (2017-08-28) [2025-10-26].. |
| [1] | Guanliang CHEN, Yi LIU, Yi YU. Heterogeneous multi-agent reinforcement learning enabled co-optimization of UAV 3D obstacle avoidance and edge computing [J]. Journal of Computer Applications, 2026, 46(9): 2898-2909. |
| [2] | Juan CHEN, Yujie CHEN, Zongling WU, Di TIAN, Jie ZHONG. User-centric satellite edge computing architecture for task offloading optimization [J]. Journal of Computer Applications, 2026, 46(8): 2524-2532. |
| [3] | Tianyu XUE, Aiping LI, Liguo DUAN. Vehicular edge computing scheme with task offloading and resource optimization [J]. Journal of Computer Applications, 2025, 45(6): 1766-1775. |
| [4] | Man CHEN, Xiaojun YANG, Huimin YANG. Pedestrian trajectory prediction based on graph convolutional network and endpoint induction [J]. Journal of Computer Applications, 2025, 45(5): 1480-1487. |
| [5] | Yufei XIANG, Zhengwei NI. Edge federation dynamic analysis for hierarchical federated learning based on evolutionary game [J]. Journal of Computer Applications, 2025, 45(4): 1077-1085. |
| [6] | Lin WEI, Shihao ZHANG, Mengyang HE. Workflow task optimization and energy-efficient offloading method for computing power network [J]. Journal of Computer Applications, 2025, 45(12): 3916-3924. |
| [7] | Jian SUN, Wei ZHANG, Baoquan MA, Zhuiwei WU, Xiaohuan YANG, Tao WU. MATOS: UAV swarm assisted moving-aware adaptive-parallel computing task offloading system [J]. Journal of Computer Applications, 2025, 45(10): 3259-3269. |
| [8] | Hailin XIAO, Tianyi HUANG, Qiuxiang DAI, Yuejun ZHANG, Zhongshan ZHANG. Safe reinforcement learning method for decision making of autonomous lane changing based on trajectory prediction [J]. Journal of Computer Applications, 2024, 44(9): 2958-2963. |
| [9] | Runze TIAN, Yulong ZHOU, Hong ZHU, Gang XUE. Local information based path selection algorithm for service migration [J]. Journal of Computer Applications, 2024, 44(7): 2168-2174. |
| [10] | Junna ZHANG, Xinxin WANG, Tianze LI, Xiaoyan ZHAO, Peiyan YUAN. Task offloading method based on dynamic service cache assistance [J]. Journal of Computer Applications, 2024, 44(5): 1493-1500. |
| [11] | Xiaoyan ZHAO, Wei HAN, Junna ZHANG, Peiyan YUAN. Collaborative offloading strategy in internet of vehicles based on asynchronous deep reinforcement learning [J]. Journal of Computer Applications, 2024, 44(5): 1501-1510. |
| [12] | Yu WANG, Zhihui GUAN, Yuanpeng LI. Distributed UAV cluster pursuit decision-making based on trajectory prediction and MADDPG [J]. Journal of Computer Applications, 2024, 44(11): 3623-3628. |
| [13] | Xiaolin LI, Yusang JIANG. Task offloading algorithm for UAV-assisted mobile edge computing [J]. Journal of Computer Applications, 2023, 43(6): 1893-1899. |
| [14] | Xiaohui HUANG, Kaiming YANG, Jiahao LING. Order dispatching by multi-agent reinforcement learning based on shared attention [J]. Journal of Computer Applications, 2023, 43(5): 1620-1624. |
| [15] | Jiagao WU, Shiwen ZHANG, Yudong JIANG, Linfeng LIU. Social-interaction GAN for pedestrian trajectory prediction based on state-refinement long short-term memory and attention mechanism [J]. Journal of Computer Applications, 2023, 43(5): 1565-1570. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
