


Journal of Computer Applications ›› 2026, Vol. 46 ›› Issue (10): 3384-3390.DOI: 10.11772/j.issn.1001-9081.2025091071
• Frontier and comprehensive applications • Previous Articles
Received:2025-09-17
Revised:2025-10-30
Accepted:2025-11-04
Online:2025-11-10
Published:2026-10-10
Contact:
Litao HAN
About author:HAN Tao, born in 2000, M. S. candidate. His research interests include indoor emergency evacuation planning.Supported by:
韩涛, 韩李涛( ), 纪然
通讯作者:
韩李涛
作者简介:韩涛(2000—),男,山东滨州人,硕士研究生,主要研究方向:室内应急疏散规划基金资助:CLC Number:
Tao HAN, Litao HAN, Ran JI. Real-time dynamic multi-source multi-sink path planning method for indoor fire scenarios[J]. Journal of Computer Applications, 2026, 46(10): 3384-3390.
韩涛, 韩李涛, 纪然. 面向室内火灾的多源多汇实时动态路径规划方法[J]. 《计算机应用》唯一官方网站, 2026, 46(10): 3384-3390.
Add to citation manager EndNote|Ris|BibTeX
URL: https://www.joca.cn/EN/10.11772/j.issn.1001-9081.2025091071
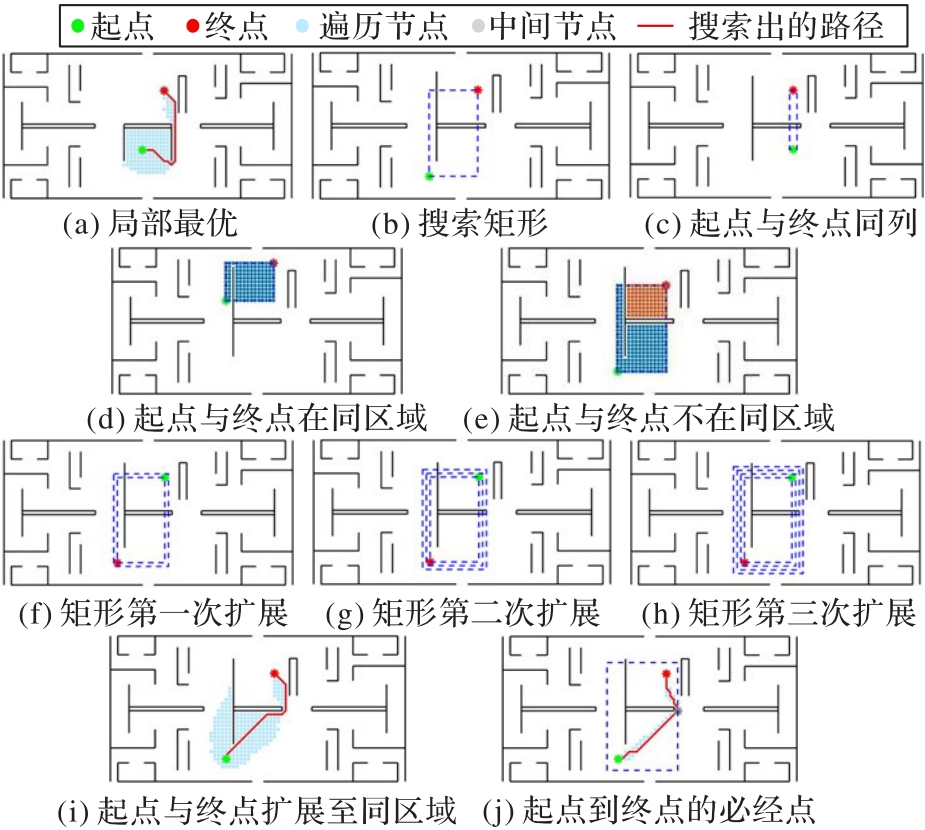
Fig. 1 Search rectangle detection mechanism
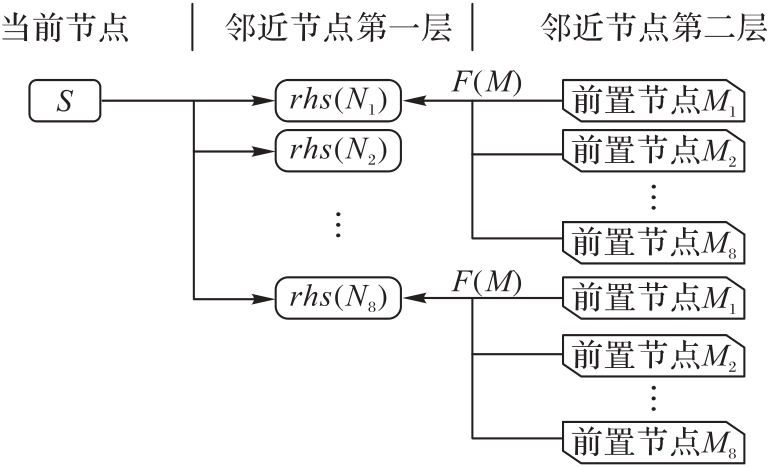
Fig. 2 Dual-layer traversal structure
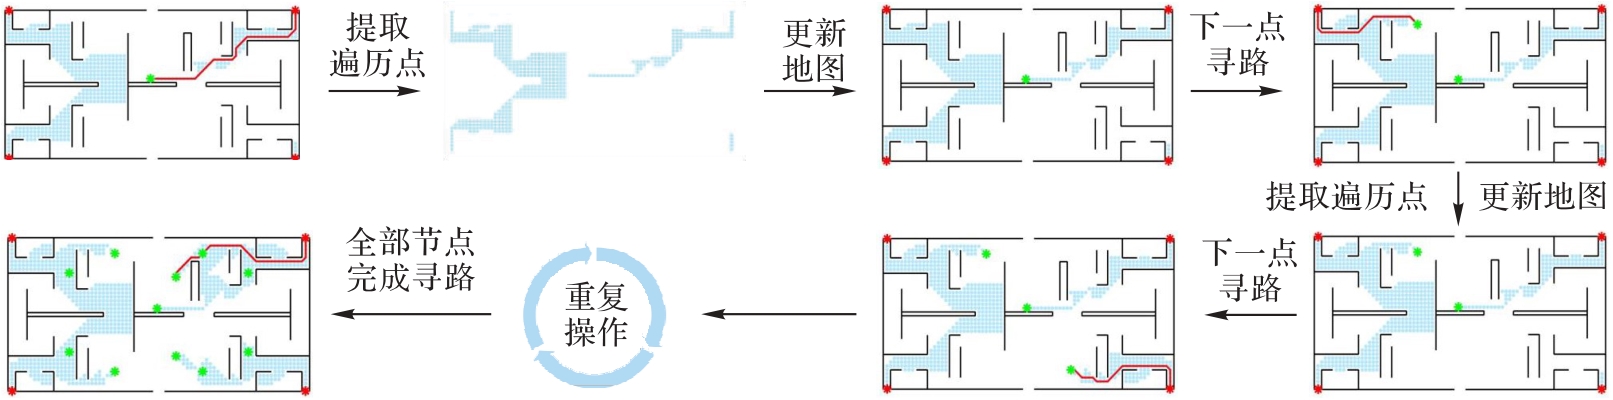
Fig. 3 Flow of sharing environment map
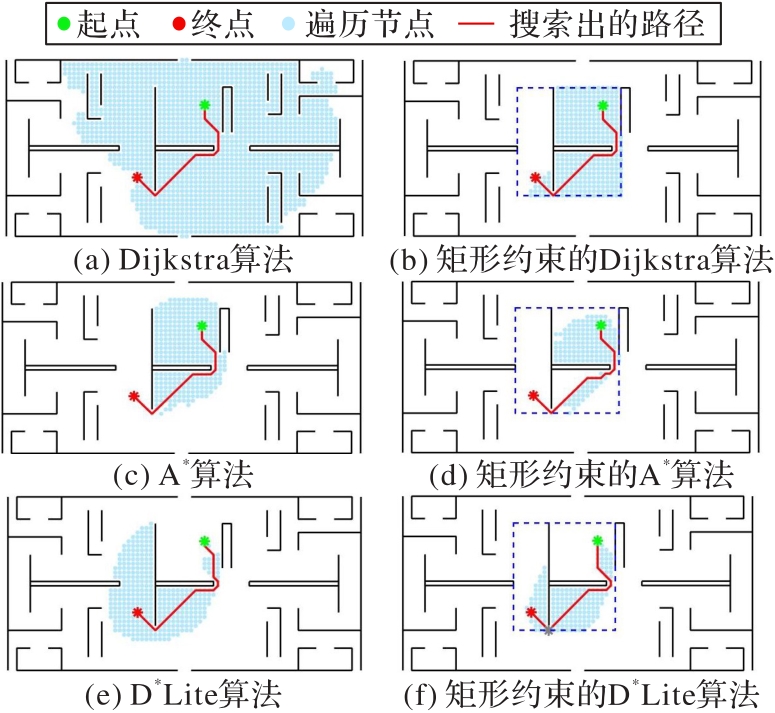
Fig. 4 Comparison of results of different algorithms
| 算法 | 路径点数 | 路径长度 | 遍历点数 | 算法耗时/s |
|---|---|---|---|---|
| Dijkstra算法 | 29 | 35.042 | 1 623 | 0.035 |
| A*算法 | 29 | 35.042 | 322 | 0.018 |
| D*Lite算法 | 29 | 35.042 | 353 | 0.029 |
| 矩形约束的Dijkstra算法 | 29 | 35.042 | 362 | 0.018 |
| 矩形约束的A*算法 | 29 | 35.042 | 182 | 0.015 |
| 矩形约束的D*Lite算法 | 29 | 35.042 | 187 | 0.026 |
Tab. 1 Performance comparison of different algorithms
| 算法 | 路径点数 | 路径长度 | 遍历点数 | 算法耗时/s |
|---|---|---|---|---|
| Dijkstra算法 | 29 | 35.042 | 1 623 | 0.035 |
| A*算法 | 29 | 35.042 | 322 | 0.018 |
| D*Lite算法 | 29 | 35.042 | 353 | 0.029 |
| 矩形约束的Dijkstra算法 | 29 | 35.042 | 362 | 0.018 |
| 矩形约束的A*算法 | 29 | 35.042 | 182 | 0.015 |
| 矩形约束的D*Lite算法 | 29 | 35.042 | 187 | 0.026 |
| [起点,终点] | D*Lite算法 | 矩形约束的D*Lite算法 | 双层搜索算法[ | |||
|---|---|---|---|---|---|---|
| 算法耗时/s | 遍历点数 | 算法耗时/s | 遍历点数 | 算法耗时/s | 遍历点数 | |
| 合计 | 0.104 | 2 262 | 0.075 | 1 622 | 10.909 | 12 374 |
| [(34,63),(13,58)] | 0.023 | 205 | 0.024 | 107 | 0.593 | 1 032 |
| [(7,27),(13,63)] | 0.008 | 104 | 0.006 | 91 | 0.279 | 646 |
| [(13,57),(28,71)] | 0.006 | 152 | 0.007 | 150 | 0.211 | 603 |
| [(8,70),(24,47)] | 0.004 | 129 | 0.004 | 129 | 0.552 | 888 |
| [(22,57),(19,57)] | 0.002 | 20 | 0.001 | 8 | 0.042 | 158 |
| [(31,132),(38,74)] | 0.008 | 222 | 0.008 | 212 | 0.674 | 1 289 |
| [(26,84),(34,33)] | 0.015 | 433 | 0.006 | 248 | 3.990 | 2 811 |
| [(33,117),(11,60)] | 0.021 | 450 | 0.013 | 430 | 2.021 | 1 923 |
| [(36,77),(30,32)] | 0.012 | 356 | 0.003 | 134 | 1.932 | 1 955 |
| [(8,48),(7,88)] | 0.005 | 191 | 0.003 | 113 | 0.615 | 1 069 |
Tab. 2 Performance of different algorithms in ten random experiments
| [起点,终点] | D*Lite算法 | 矩形约束的D*Lite算法 | 双层搜索算法[ | |||
|---|---|---|---|---|---|---|
| 算法耗时/s | 遍历点数 | 算法耗时/s | 遍历点数 | 算法耗时/s | 遍历点数 | |
| 合计 | 0.104 | 2 262 | 0.075 | 1 622 | 10.909 | 12 374 |
| [(34,63),(13,58)] | 0.023 | 205 | 0.024 | 107 | 0.593 | 1 032 |
| [(7,27),(13,63)] | 0.008 | 104 | 0.006 | 91 | 0.279 | 646 |
| [(13,57),(28,71)] | 0.006 | 152 | 0.007 | 150 | 0.211 | 603 |
| [(8,70),(24,47)] | 0.004 | 129 | 0.004 | 129 | 0.552 | 888 |
| [(22,57),(19,57)] | 0.002 | 20 | 0.001 | 8 | 0.042 | 158 |
| [(31,132),(38,74)] | 0.008 | 222 | 0.008 | 212 | 0.674 | 1 289 |
| [(26,84),(34,33)] | 0.015 | 433 | 0.006 | 248 | 3.990 | 2 811 |
| [(33,117),(11,60)] | 0.021 | 450 | 0.013 | 430 | 2.021 | 1 923 |
| [(36,77),(30,32)] | 0.012 | 356 | 0.003 | 134 | 1.932 | 1 955 |
| [(8,48),(7,88)] | 0.005 | 191 | 0.003 | 113 | 0.615 | 1 069 |
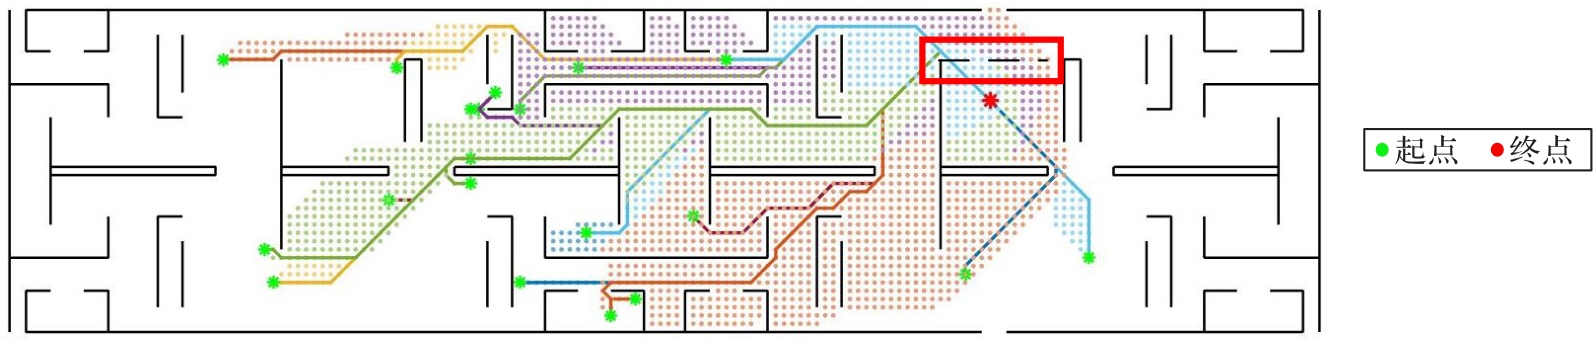
Fig. 5 Path planning map with twenty source points
| 算法 | 图5地图算法平均耗时/s | 对比地图算法平均耗时/s | 图5地图标准差 | 对比地图标准差 |
|---|---|---|---|---|
| D*Lite算法 | 0.481 | 0.642 | 0.016 | 0.015 |
| 矩形约束的D*Lite算法 | 0.296 | 0.478 | 0.011 | 0.018 |
| 共享环境图D*Lite算法 | 0.151 | 0.174 | 0.014 | 0.013 |
| RCSM-D*Lite算法 | 0.134 | 0.166 | 0.013 | 0.016 |
Tab. 3 Performance comparison of algorithms in different maps
| 算法 | 图5地图算法平均耗时/s | 对比地图算法平均耗时/s | 图5地图标准差 | 对比地图标准差 |
|---|---|---|---|---|
| D*Lite算法 | 0.481 | 0.642 | 0.016 | 0.015 |
| 矩形约束的D*Lite算法 | 0.296 | 0.478 | 0.011 | 0.018 |
| 共享环境图D*Lite算法 | 0.151 | 0.174 | 0.014 | 0.013 |
| RCSM-D*Lite算法 | 0.134 | 0.166 | 0.013 | 0.016 |
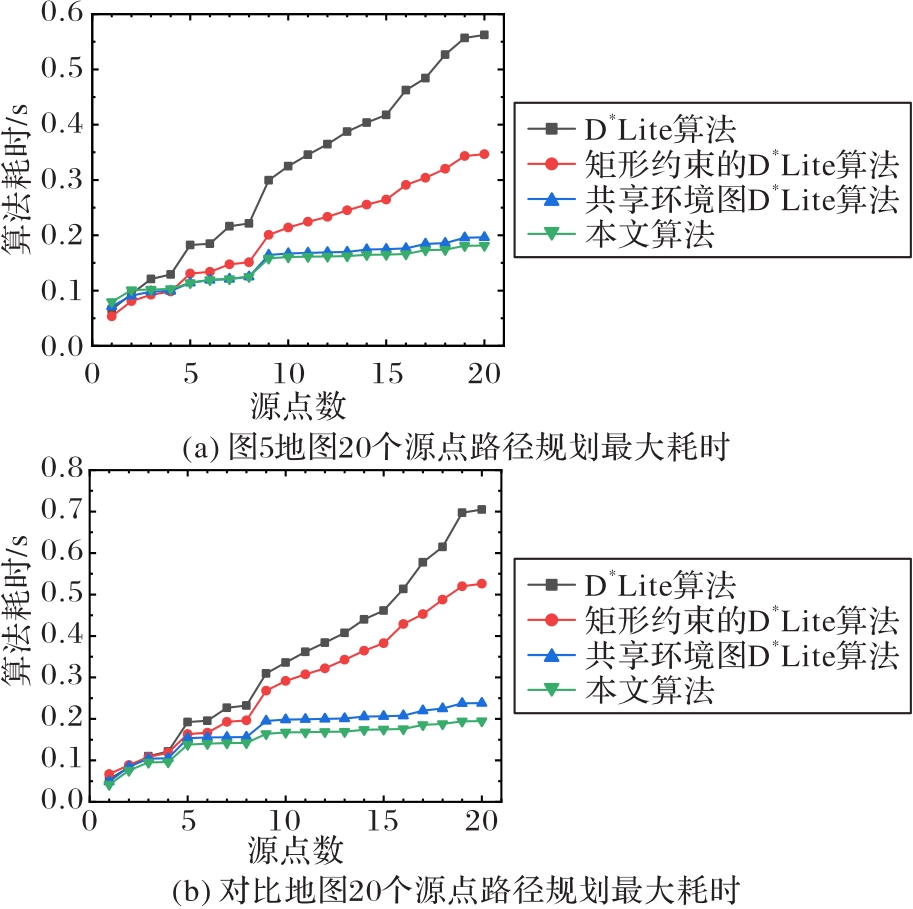
Fig. 6 Max running time comparison of algorithms in different maps
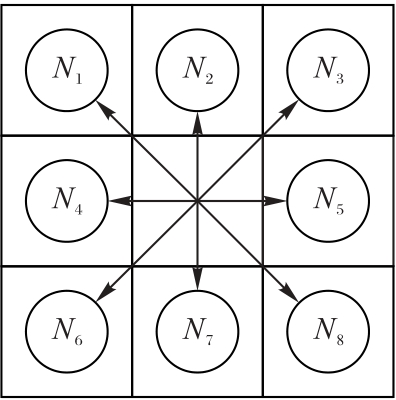
Fig. 7 Eight-directional movement model
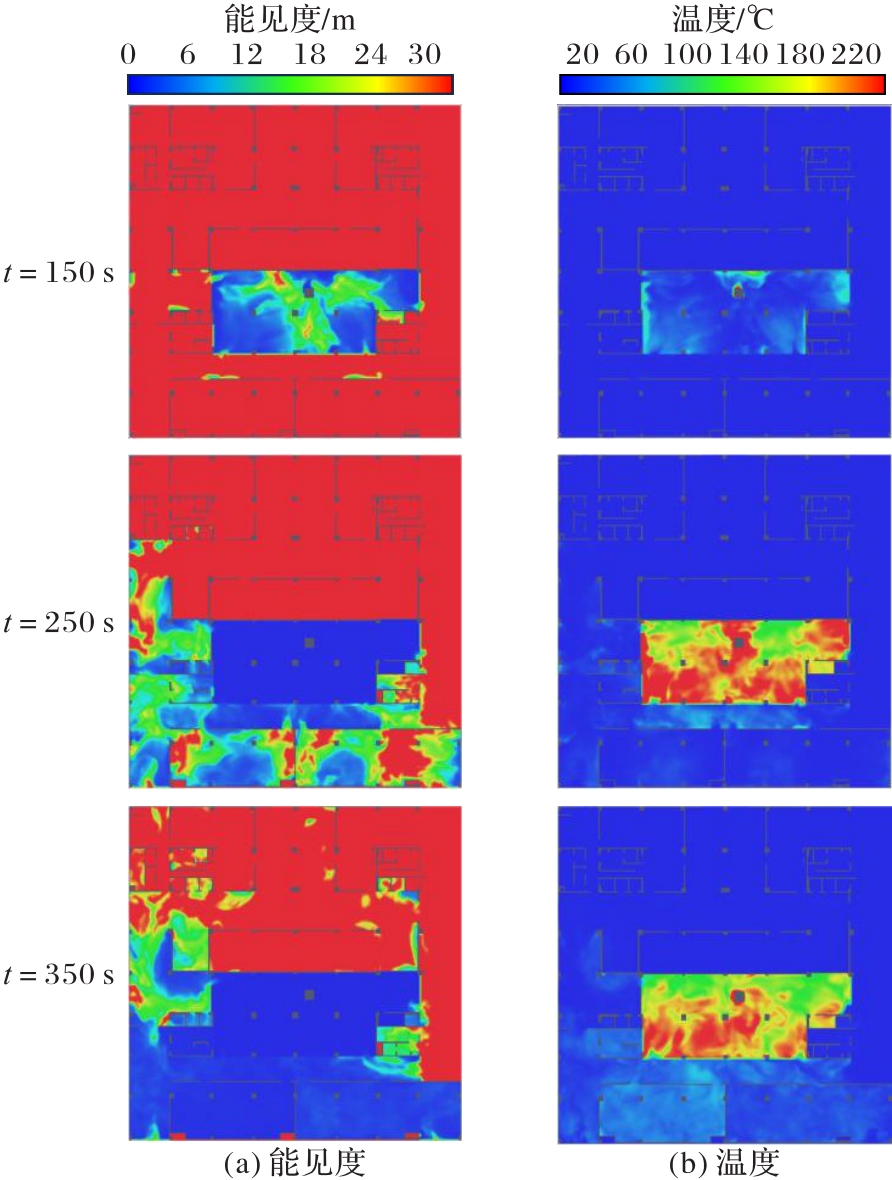
Fig. 8 Experimental data of fire
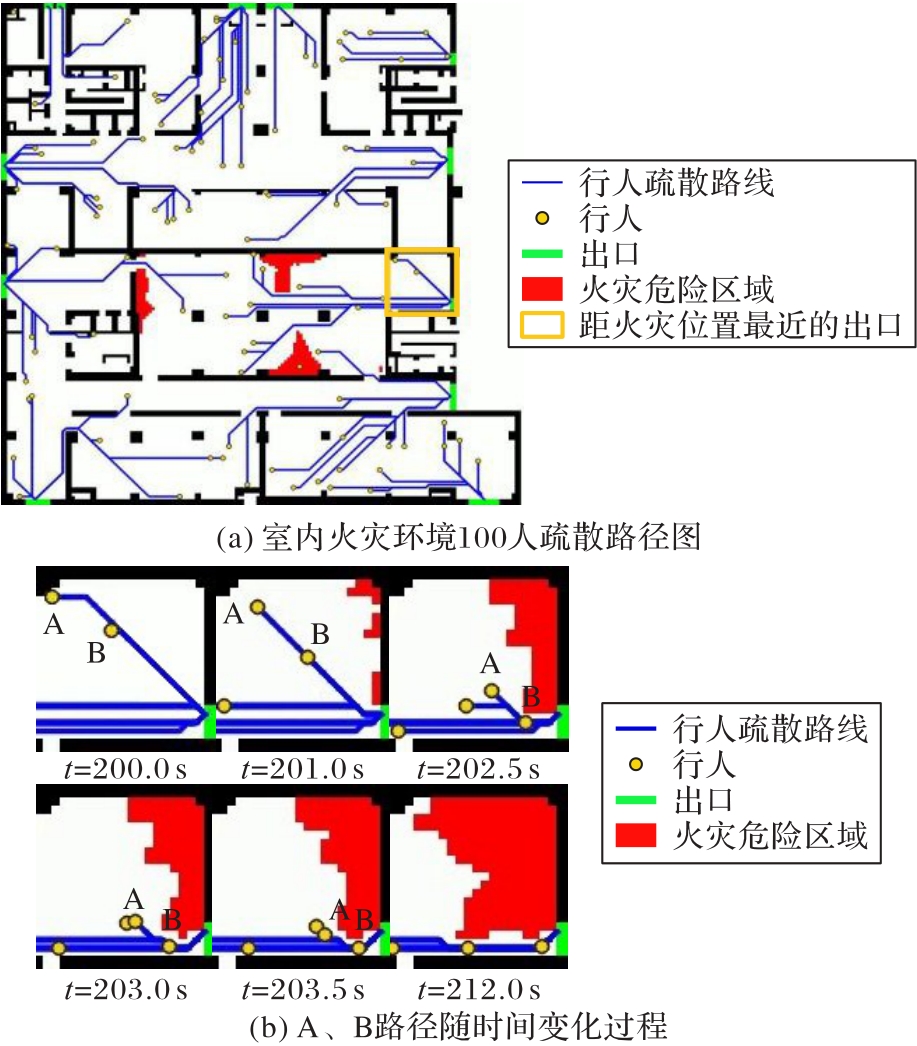
Fig. 9 Dynamic paths of pedestrian evacuation
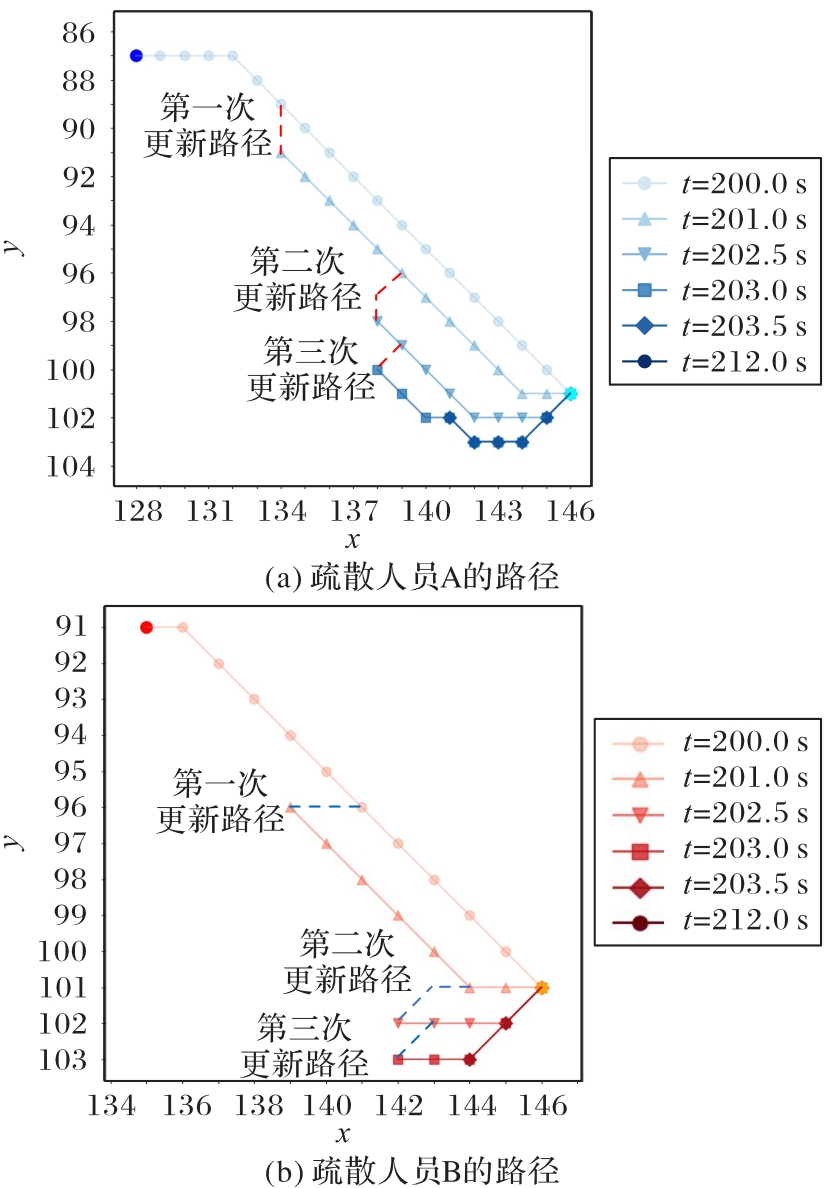
Fig. 10 Comparison of dynamic path changes of evacuees
| [1] | 俞凯,刘萍萍,周鲁洁. 长廊型教学楼火灾疏散模拟及对策研究[J]. 消防科学与技术, 2025, 44(3): 340-346. |
| Yu Kai, Liu Pingping, Zhou Lujie. Fire evacuation simulation and countermeasures research in a long corridor-type academic buildings[J]. Fire Science and Technology, 2025, 44(3): 340-346. | |
| [2] | Luo M, Hou X, Yang J. Surface optimal path planning using an extended Dijkstra algorithm[J]. IEEE Access, 2020, 8: 147827-147838. |
| [3] | Wang C, Wang L, Qin J, et al. Path planning of automated guided vehicles based on improved A-star algorithm[C]// ICIA 2015. Piscataway: IEEE, 2015: 2071-2076. |
| [4] | Sarbini R N, Ahmad I, Bura R O, et al. Development of pathfinding using A-star and D-star lite algorithms in video game[J]. Journal of Theoretical and Applied Information Technology, 2024, 102(3): 832-841. |
| [5] | Liu J, Yang J, Liu H, et al. An improved ant colony algorithm for robot path planning[J]. Soft Computing, 2017, 21(19): 5829-5839. |
| [6] | Lyu D, Chen Z, Cai Z, et al. Robot path planning by leveraging the graph-encoded Floyd algorithm[J]. Future Generation Computer Systems, 2021, 122: 204-208. |
| [7] | Koenig S, Likhachev M. Fast replanning for navigation in unknown terrain[J]. IEEE Transactions on Robotics, 2005, 21(3): 354-363. |
| [8] | 张华军,刘洋,朱震宇,等. 邮轮火灾动态蔓延情况下的最优疏散路径规划[J]. 中国安全科学学报, 2023, 33(1): 183-190. |
| Zhang Huajun, Liu Yang, Zhu Zhenyu, et al. Optimal evacuation path planning under dynamic spreading of cruise ship fire[J]. China Safety Science Journal, 2023, 33(1): 183-190. | |
| [9] | Han B, Qu T, Tong X, et al. Grid-optimized UAV indoor path planning algorithms in a complex environment[J]. International Journal of Applied Earth Observation and Geoinformation, 2022, 111: No.102857. |
| [10] | 蒙盾,胡卓,张华军. 基于改进A*算法的多层邮轮疏散系统仿真[J]. 系统仿真学报, 2022, 34(6): 1375-1382. |
| Meng Dun, Hu Zhuo, Zhang Huajun. Simulation of multi-layer ship evacuation system based on improved A* algorithm[J]. Journal of System Simulation, 2022, 34(6): 1375-1382. | |
| [11] | Liu Z, Liu H, Lu Z, et al. A dynamic fusion pathfinding algorithm using Delaunay triangulation and improved A-star for mobile robots[J]. IEEE Access, 2021, 9: 20602-20621. |
| [12] | Liu L, Wang B, Xu H. Research on path-planning algorithm integrating optimization A-star algorithm and artificial potential field method[J]. Electronics, 2022, 11(22): No.3660. |
| [13] | Ferguson D, Stentz A. The delayed D* algorithm for efficient path replanning[C]// ICRA 2005. Piscataway: IEEE, 2005: 2045-2050. |
| [14] | 李墨潇,张建辉,王晟旻,等. 基于改进D*Lite算法的疏散路径规划方法研究[J]. 中国安全生产科学技术, 2025, 21(3): 42-49. |
| Li Moxiao, Zhang Jianhui, Wang Shengmin, et al. Research on evacuation path planning method based on improved D*Lite algorithm[J]. Journal of Safety Science and Technology, 2025, 21(3): 42-49. | |
| [15] | 刘毅,沈斐敏. 考虑灾害实时扩散的室内火灾疏散路径选择模型[J]. 控制与决策, 2018, 33(9): 1598-1604. |
| Liu Yi, Shen Feimin. Route selection model in indoor evacuation under real effect of fire spread[J]. Control and Decision, 2018, 33(9): 1598-1604. | |
| [16] | 刘军,冯硕,任建华. 移动机器人路径动态规划有向D*算法[J]. 浙江大学学报(工学版), 2020, 54(2): 291-300. |
| Liu Jun, Feng Shuo, Ren Jianhua. Directed D* algorithm for dynamic path planning of mobile robots[J]. Journal of Zhejiang University (Engineering Science), 2020, 54(2): 291-300. | |
| [17] | 鞠慕涵,刘万科,胡捷,等. 改进D*算法的未知场景机器人运动规划[J]. 导航定位学报, 2024, 12(3): 145-153. |
| Ju Muhan, Liu Wanke, Hu Jie, et al. Motion planning for robots in unknown scenes based on improved D* algorithm[J]. Journal of Navigation and Positioning, 2024, 12(3): 145-153. | |
| [18] | LaValle S M. Rapidly-exploring random trees: a new tool for path planning[R/OL]. [2025-07-17].. |
| [19] | 陈小龙,李明智,汪雅琴,等. 基于人工势场法改进RRT*算法的无人船路径规划[J]. 舰船科学技术, 2026, 48(5): 151-157. |
| Chen Xiaolong, Li Mingzhi, Wang Yaqin, et al. Unmanned ship path planning based on the improved RRT* algorithm of artificial potential field method[J]. Ship Science and Technology, 2026, 48(5): 151-157. | |
| [20] | Xu T, Ma J, Qin P, et al. An improved RRT* algorithm based on adaptive informed sample strategy for coastal ship path planning[J]. Ocean Engineering, 2025, 333: No.121511. |
| [21] | 韩李涛,郭欢,张海思. 一种多出口室内应急疏散路径规划算法[J]. 测绘科学, 2018, 43(12): 105-110. |
| Han Litao, Guo Huan, Zhang Haisi. An algorithm for route planning applied in multi-exit indoor emergency evacuation[J]. Science of Surveying and Mapping, 2018, 43(12): 105-110. | |
| [22] | 钟委,霍然,史聪灵. 热释放速率设定方式的几点讨论[J]. 自然灾害学报, 2004, 13(2): 64-69. |
| Zhong Wei, Huo Ran, Shi Congling. Some discussion on methodology to design heat release rate[J]. Journal of Natural Disasters, 2004, 13(2): 64-69. | |
| [23] | 李明海,兰亚乐,马骁,等. 建筑火灾全局动态疏散路径规划研究[J]. 安全与环境学报, 2025, 25(1): 205-215. |
| Li Minghai, Lan Yale, Ma Xiao, et al. Research on global dynamic path planning for evacuation during building fires[J]. Journal of Safety and Environment, 2025, 25(1): 205-215. | |
| [24] | 倪凌佳,黄晓霞,李红旮,等. 基于协作式深度强化学习的火灾应急疏散仿真研究[J]. 系统仿真学报, 2022, 34(6): 1353-1366. |
| Ni Lingjia, Huang Xiaoxia, Li Hongga, et al. Research on fire emergency evacuation simulation based on cooperative deep reinforcement learning[J]. Journal of System Simulation, 2022, 34(6): 1353-1366. | |
| [25] | 谢玮,张玉春. 能见度对个体疏散速度及路径选择的影响研究[J]. 中国安全生产科学技术, 2017, 13(7): 62-67. |
| Xie Wei, Zhang Yuchun. Experimental study on impact of visibility on individual evacuation speed and path selection[J]. Journal of Safety Science and Technology, 2017, 13(7): 62-67. |
| [1] | Jingying XUE, Liqun KUANG, Zhixun WANG, Zhengtao GUO, Huiyan HAN. Multi-agent path planning with hierarchical adaptive implicit quantiles [J]. Journal of Computer Applications, 2026, 46(8): 2533-2540. |
| [2] | Xingwang WANG, Qingyang ZHANG, Shouyong JIANG, Yongquan DONG. Dynamic UAV path planning based on modified whale optimization algorithm [J]. Journal of Computer Applications, 2025, 45(3): 928-936. |
| [3] | Suqian WU, Jianguo YAN, Bin YANG, Tao QIN, Ying LIU, Jing YANG. Multi-strategy improved Aquila optimizer and its application in path planning [J]. Journal of Computer Applications, 2025, 45(3): 937-945. |
| [4] | Caiqi WANG, Xining CUI, Yi XIONG, Shiqian WU. Adaptive extended RRT* path planning algorithm based on node-to-obstacle distance [J]. Journal of Computer Applications, 2025, 45(3): 920-927. |
| [5] | Yu WANG, Mingyue ZHAO, Xiaolin ZHOU. Task-based assistive robot path planning in nursing home scenarios [J]. Journal of Computer Applications, 2025, 45(10): 3270-3276. |
| [6] | Yi RAN, Yongsheng LI, Ye JIANG. Addressing robot path planning issues using S-shaped growth curve integrated grasshopper optimization algorithm [J]. Journal of Computer Applications, 2025, 45(1): 178-185. |
| [7] | Runze TIAN, Yulong ZHOU, Hong ZHU, Gang XUE. Local information based path selection algorithm for service migration [J]. Journal of Computer Applications, 2024, 44(7): 2168-2174. |
| [8] | Tian MA, Runtao XI, Jiahao LYU, Yijie ZENG, Jiayi YANG, Jiehui ZHANG. Mobile robot 3D space path planning method based on deep reinforcement learning [J]. Journal of Computer Applications, 2024, 44(7): 2055-2064. |
| [9] | Jianqiang LI, Zhou HE. Hybrid NSGA-Ⅱ for vehicle routing problem with multi-trip pickup and delivery [J]. Journal of Computer Applications, 2024, 44(4): 1187-1194. |
| [10] | Haixin HUANG, Guangwei YU, Shoushan CHENG, Chunming LI. Full coverage path planning of bridge inspection wall-climbing robot based on improved grey wolf optimization [J]. Journal of Computer Applications, 2024, 44(3): 966-971. |
| [11] | Ziyang SONG, Junhuai LI, Huaijun WANG, Xin SU, Lei YU. Path planning algorithm of manipulator based on path imitation and SAC reinforcement learning [J]. Journal of Computer Applications, 2024, 44(2): 439-444. |
| [12] | Jian SUN, Baoquan MA, Zhuiwei WU, Xiaohuan YANG, Tao WU, Pan CHEN. Joint optimization of UAV swarm path planning and task allocation balance in earthquake scenarios [J]. Journal of Computer Applications, 2024, 44(10): 3232-3239. |
| [13] | Yongdi LI, Caihong LI, Yaoyu ZHANG, Guosheng ZHANG. Mobile robot path planning based on improved SAC algorithm [J]. Journal of Computer Applications, 2023, 43(2): 654-660. |
| [14] | Lin HUANG, Qiang FU, Nan TONG. Solving robot path planning problem by adaptively adjusted Harris hawk optimization algorithm [J]. Journal of Computer Applications, 2023, 43(12): 3840-3847. |
| [15] | Chen LIU, Yang CHEN, Hao FU. UAV path planning for persistent monitoring based on value function iteration [J]. Journal of Computer Applications, 2023, 43(10): 3290-3296. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
